MAMS-A*
C++Multi-Resolution Multi-Agent A* Algorithm (ICRA 2020) for shortest path planning in multi-scale graphs.
Open-source software developed by the Dynamics and Control Systems Laboratory for research and education in autonomous systems.
Multi-Resolution Multi-Agent A* Algorithm (ICRA 2020) for shortest path planning in multi-scale graphs.
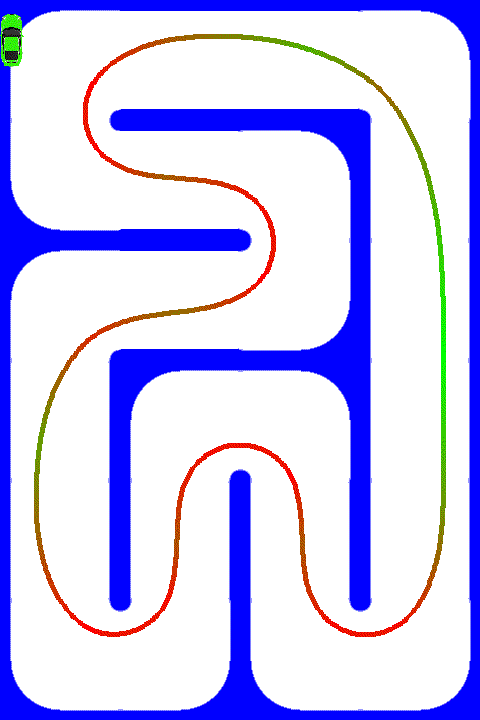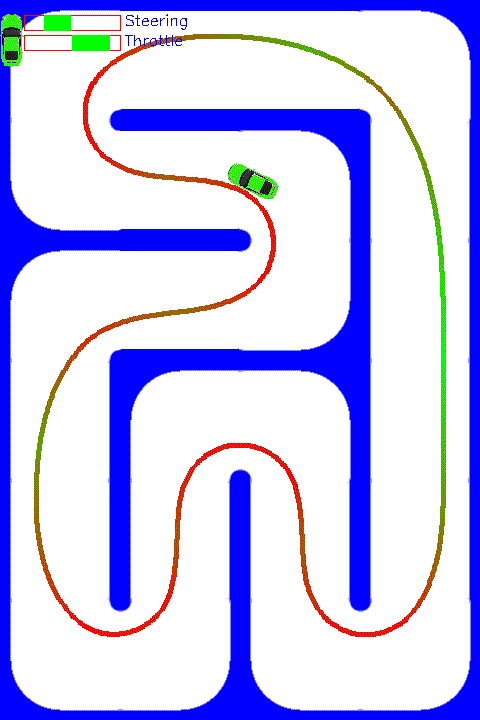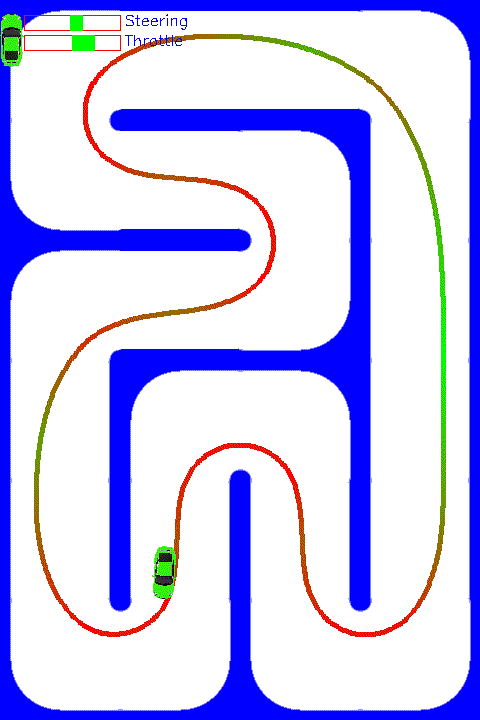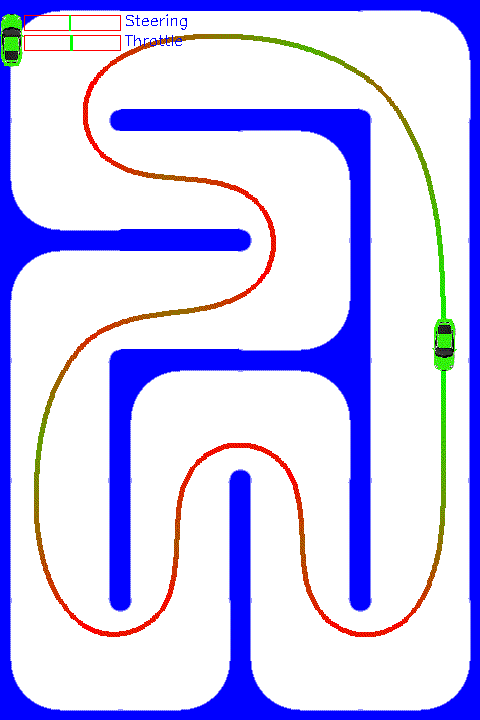
A 1/28 scale autonomous vehicle platform for education and research, supporting both simulation and hardware.
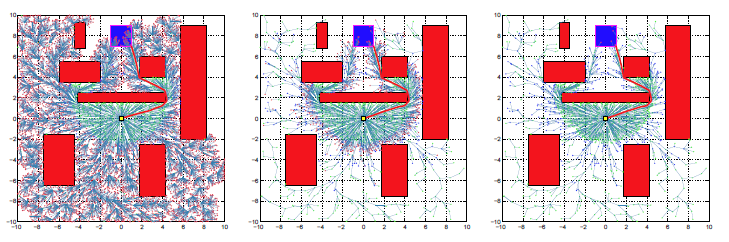
An implementation of the RRT# planning algorithm for optimal motion planning.
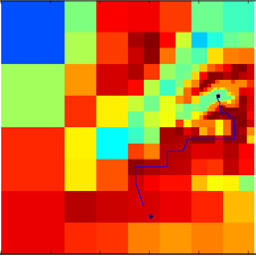
Multiresolution Motion Planning for Autonomous Agents via Wavelet-Based Cell Decompositions.
Implementation of advanced planning for autonomous vehicles using Reinforcement Learning and Deep Inverse RL.
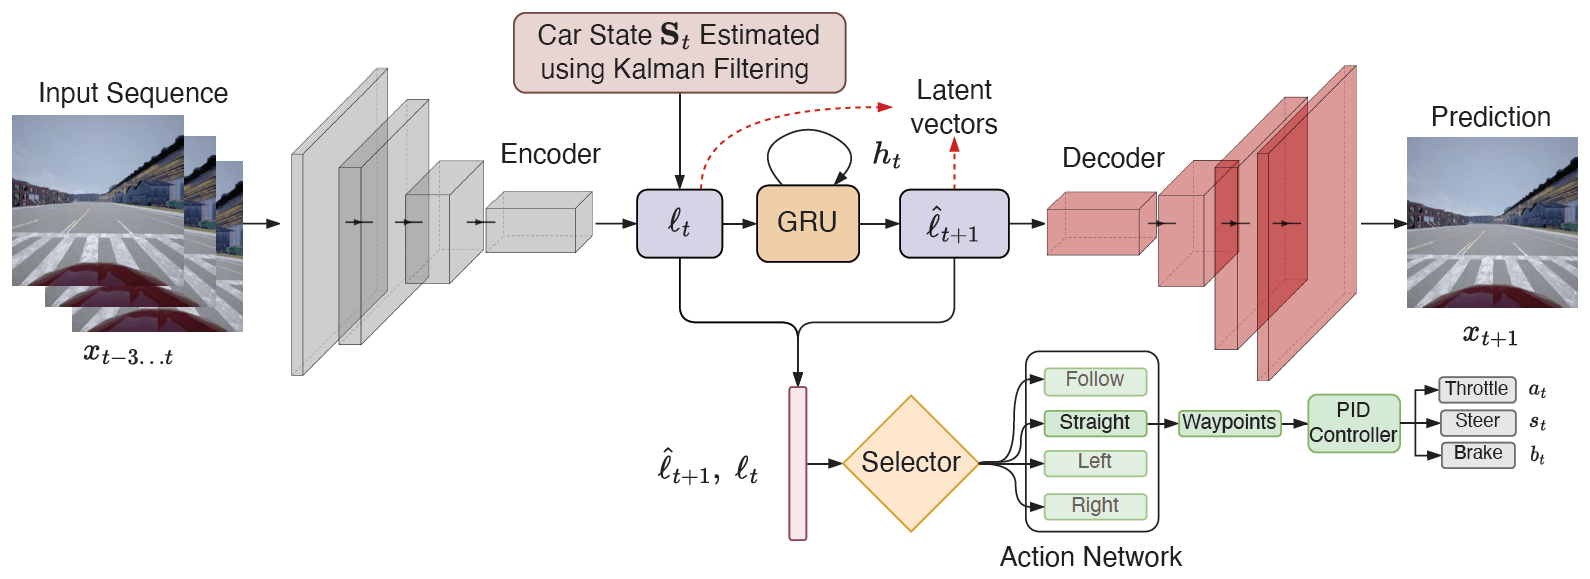
Kalman filter augmented recurrent network that learns a world model for autonomous driving from front-camera images.
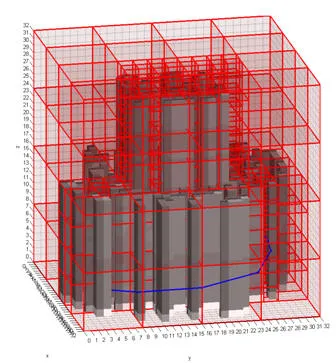
Builds a beamlet graph for shortest-path problems with curvature constraints, from the IROS 2011 paper by Arslan, Tsiotras and Huo.
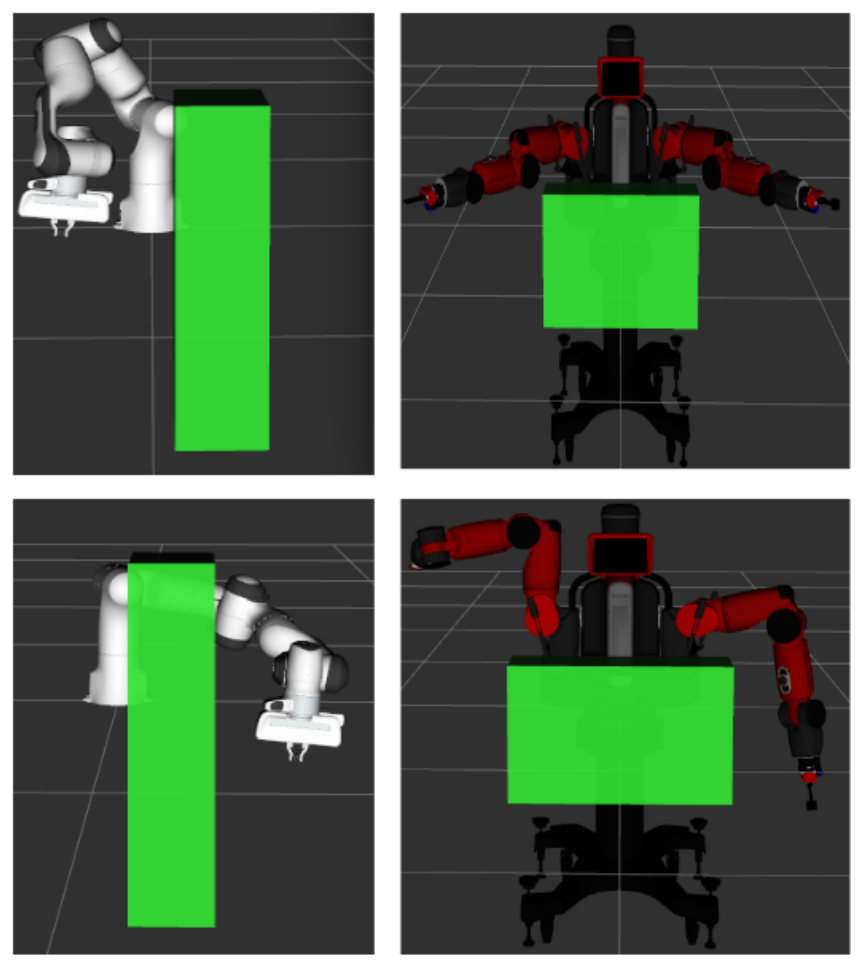
Locally Exploitative Sampling for robot path planning, implemented as a set of OMPL planners.
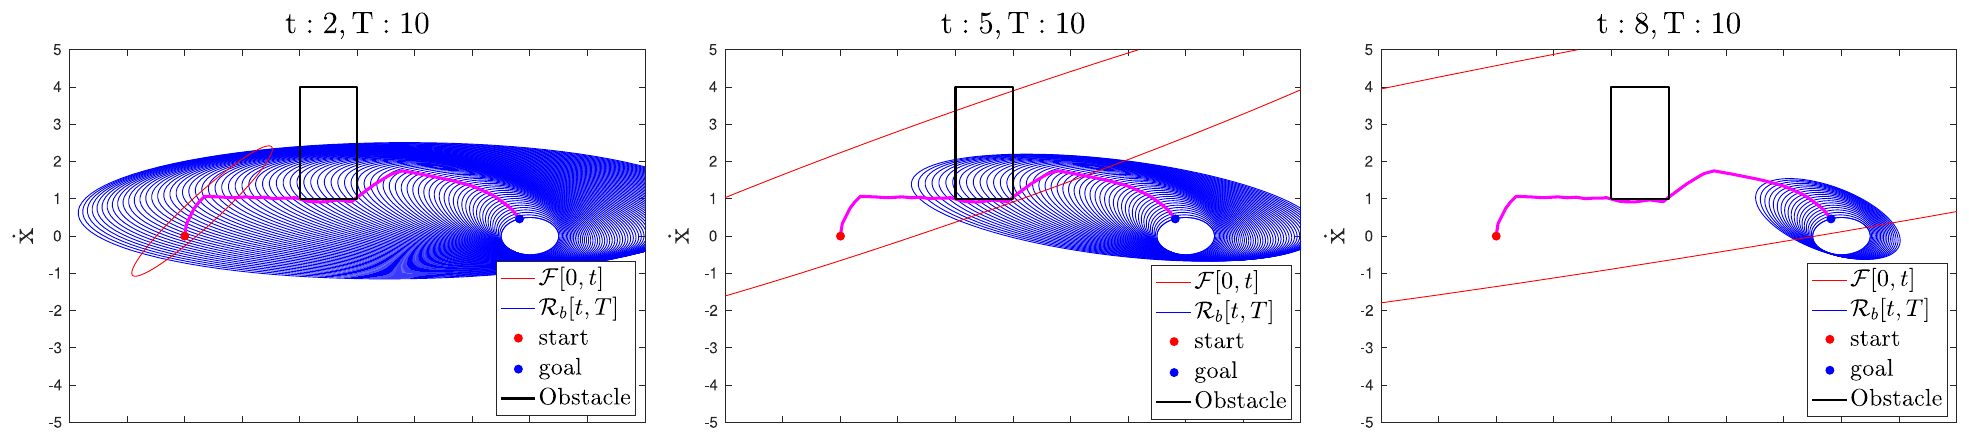
Time-Informed Exploration: reachability-based focusing of the search for sampling-based kinodynamic planning.
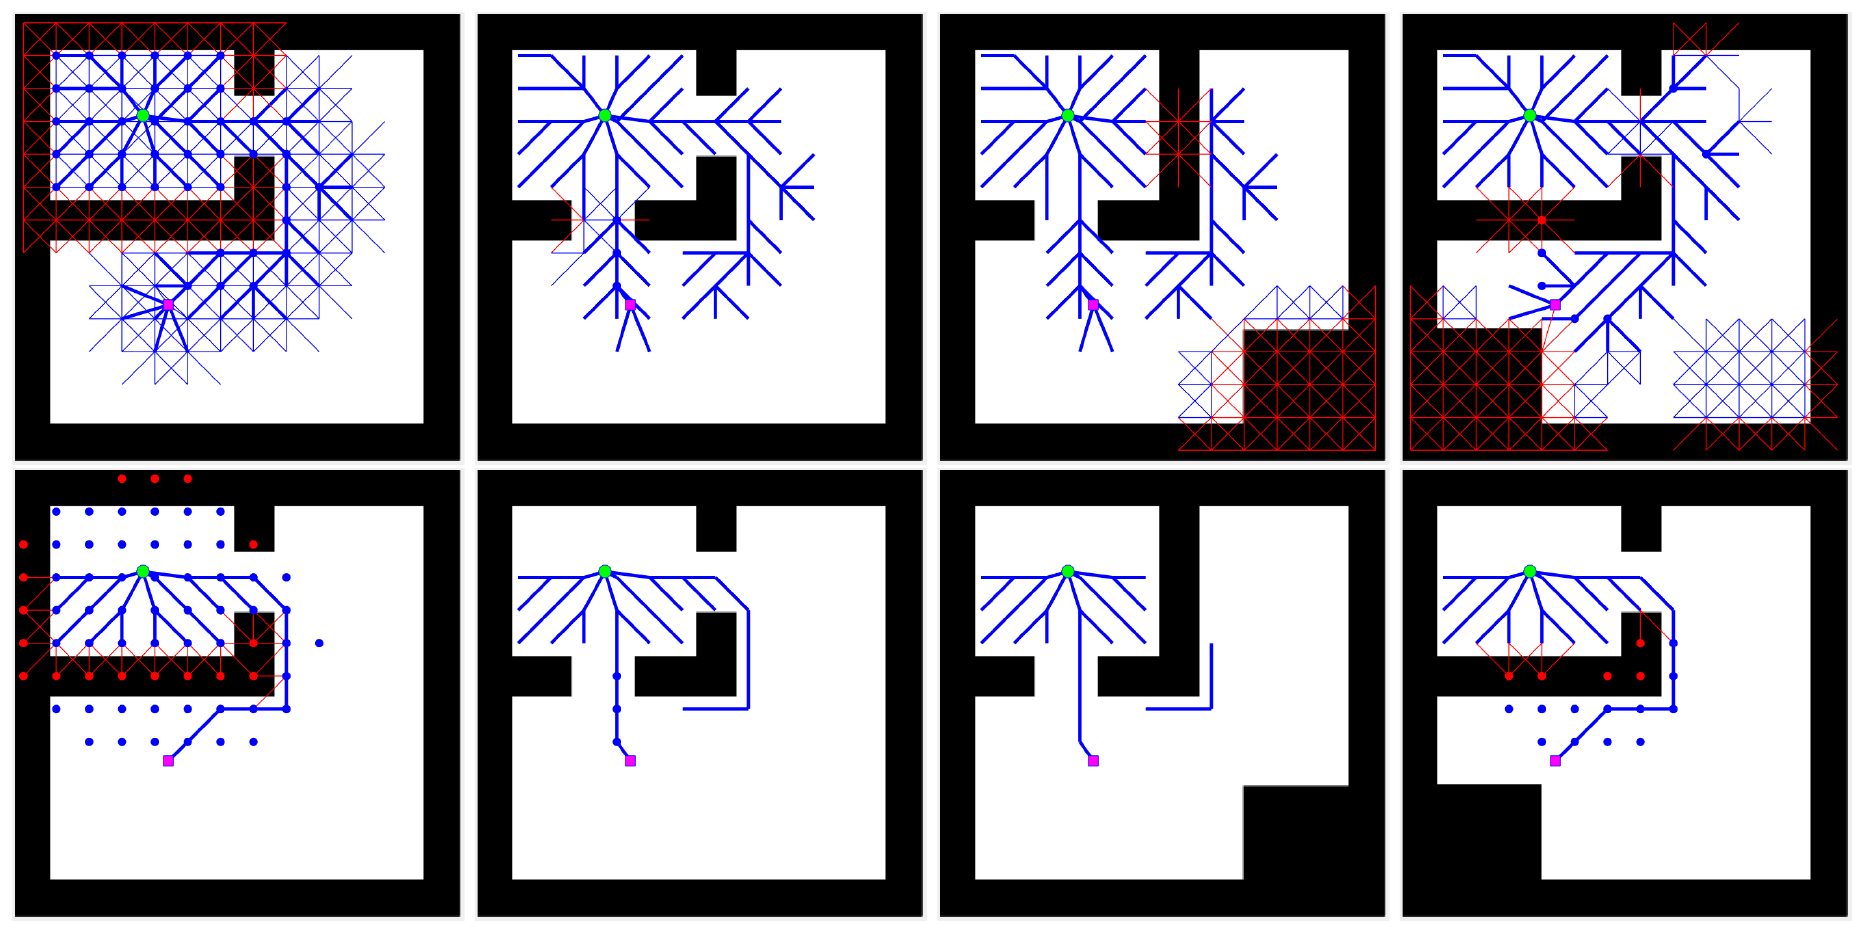
A framework of lazy search algorithms implemented in OMPL, including Lifelong Planning A*, Generalized Lazy Search and Lifelong-GLS.
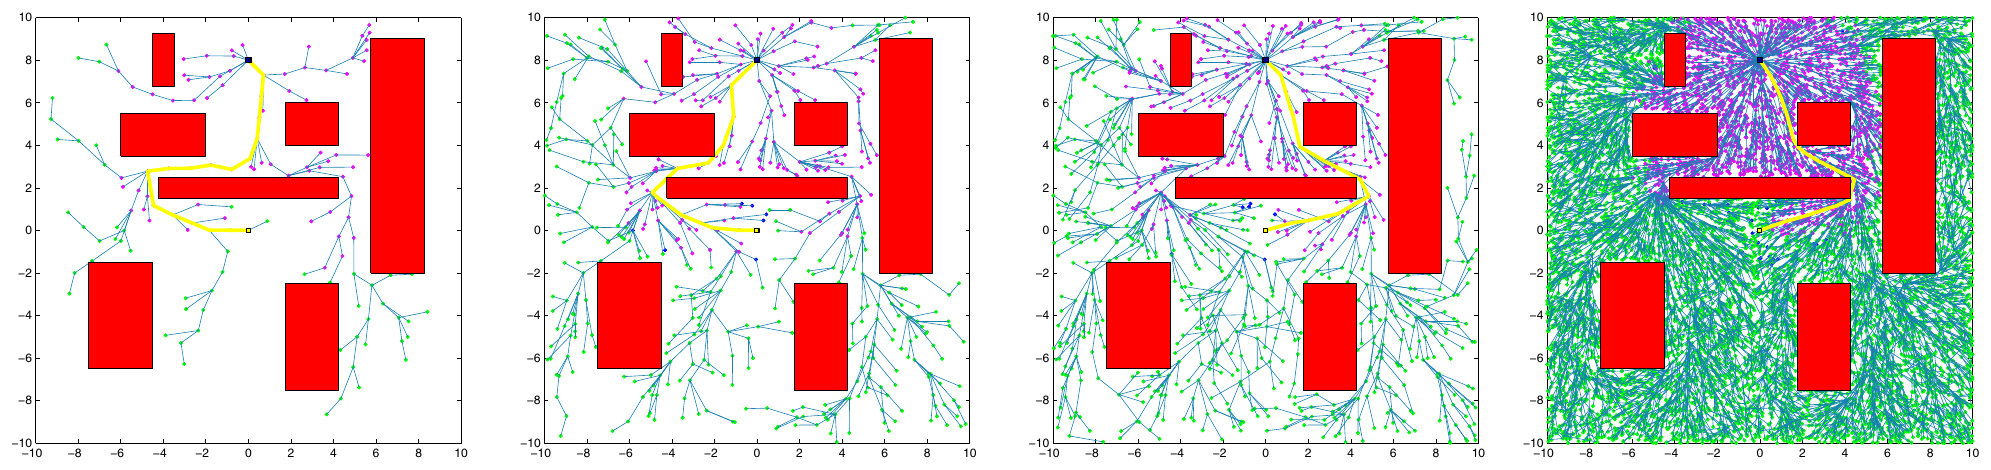
A parallelised PI-RRT# implementation in CUDA, written without OMPL structures.
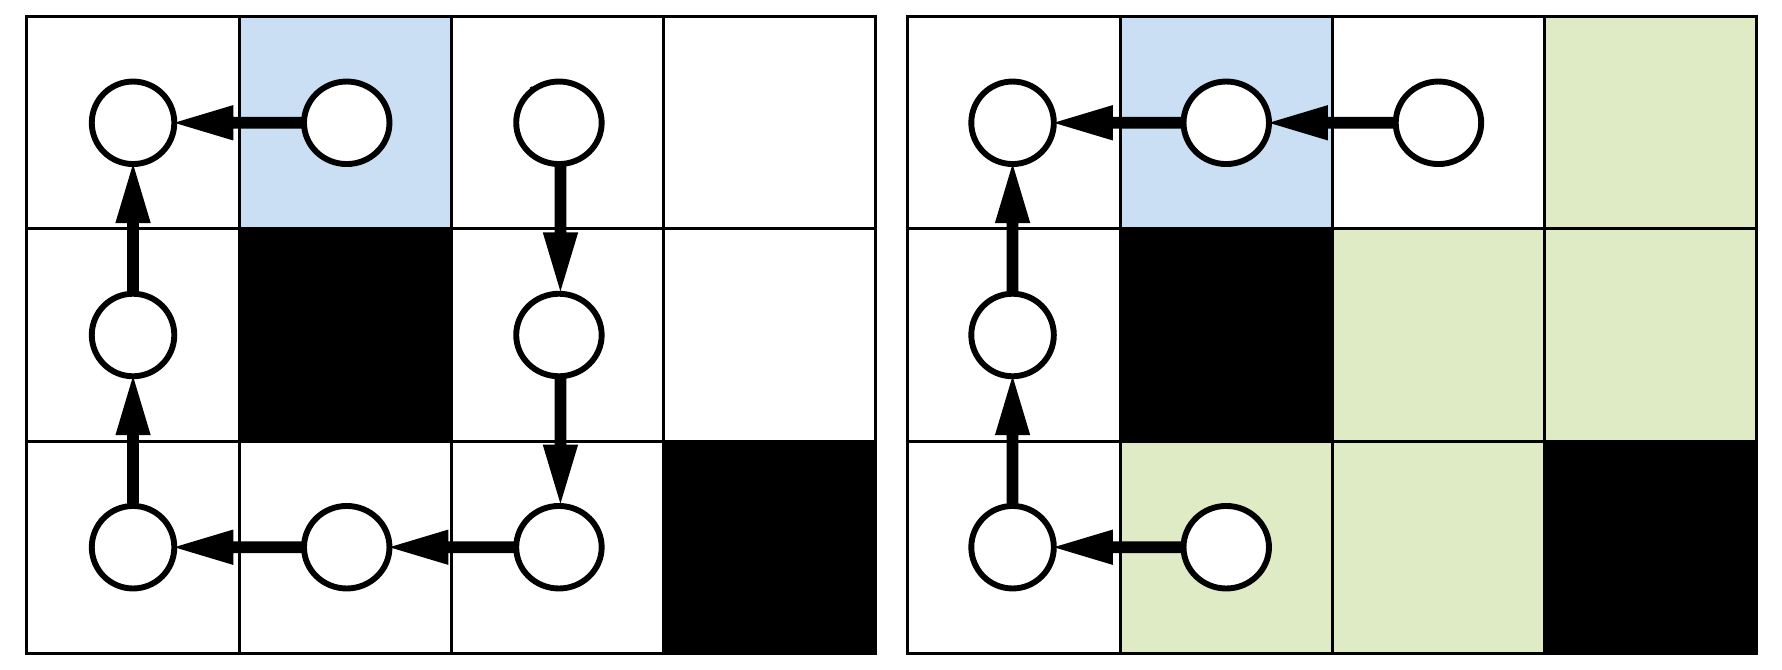
CBS-Budget: a complete and bounded-suboptimal search for multi-agent path finding.
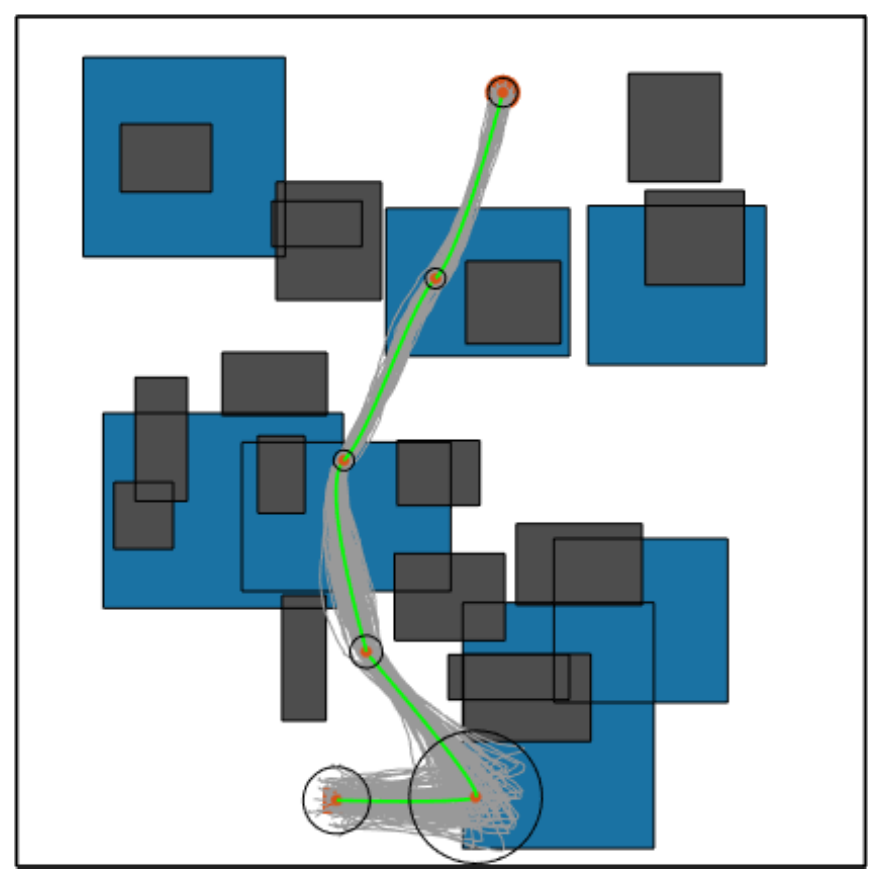
Informed Batch Belief Trees for motion planning under motion and sensing uncertainty.
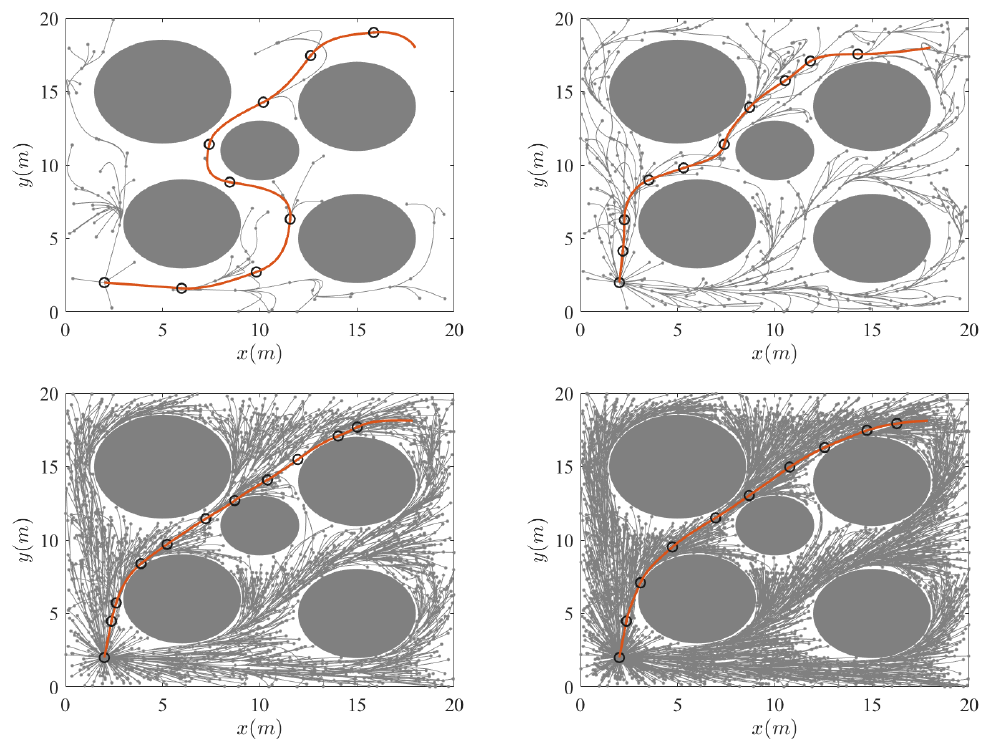
Kinodynamic RRT* accelerated by dimensionality reduction, using a partial-final-state-free optimal controller.
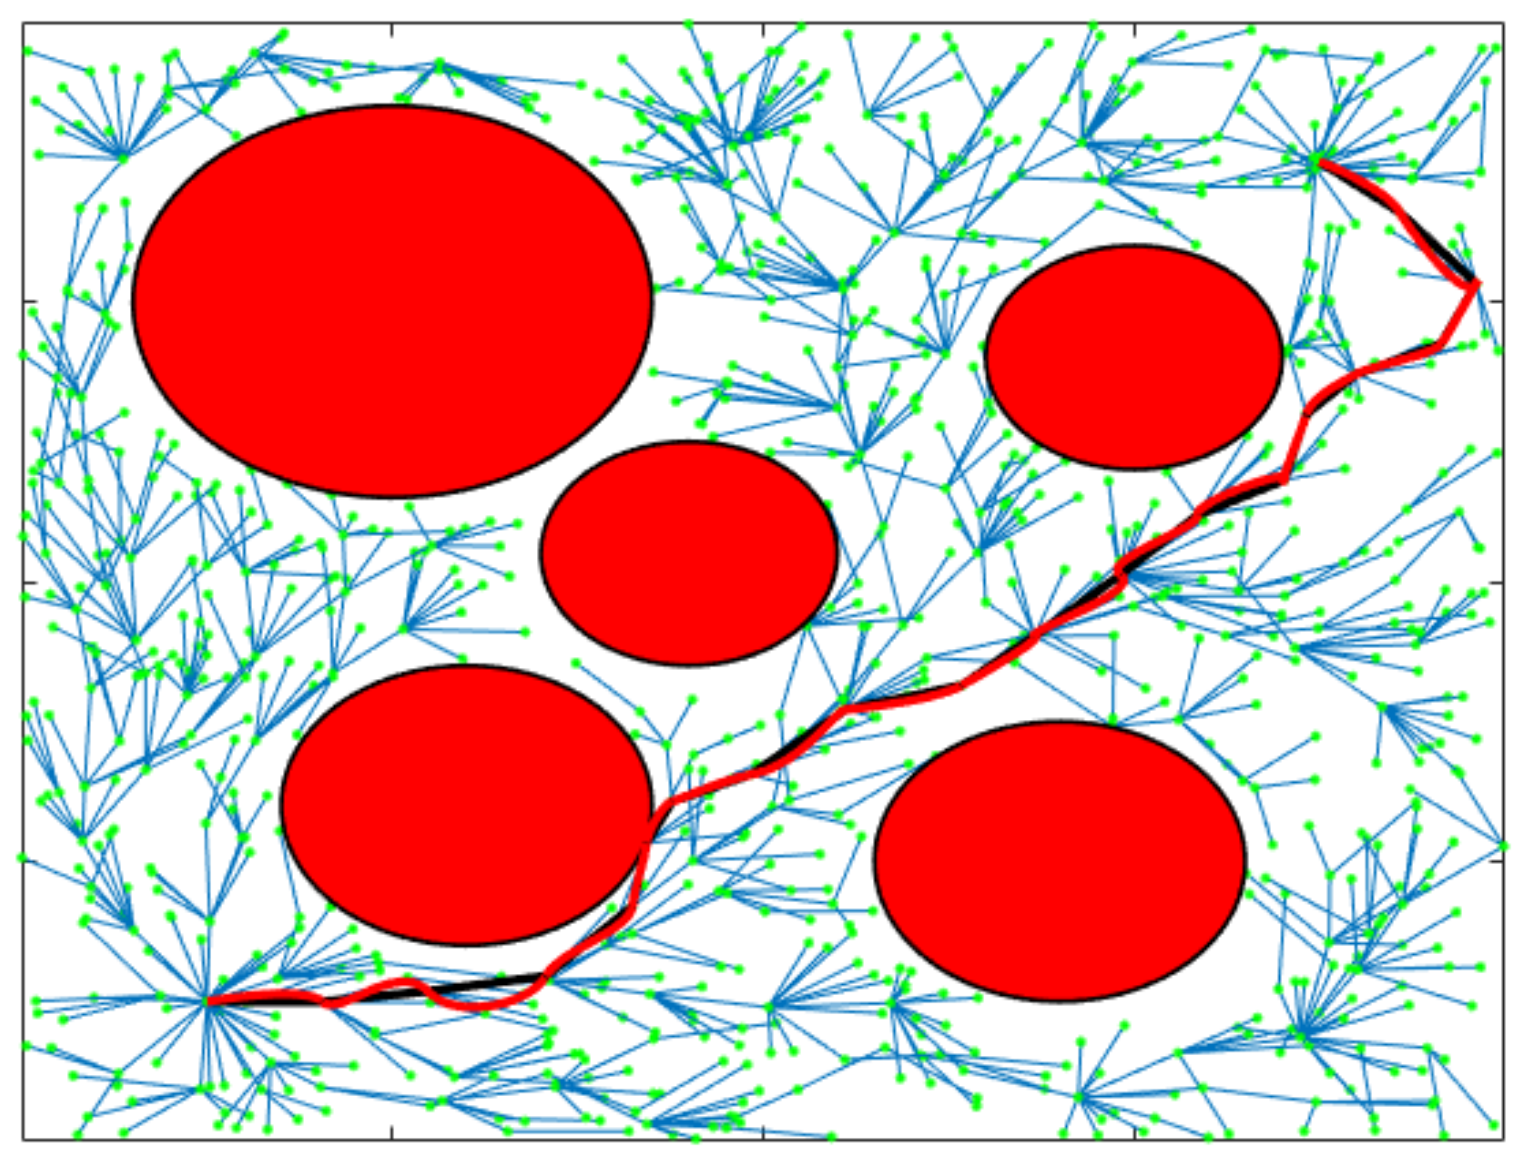
Sampling-based kinodynamic motion planning in which the steering function is a learned neural network controller.
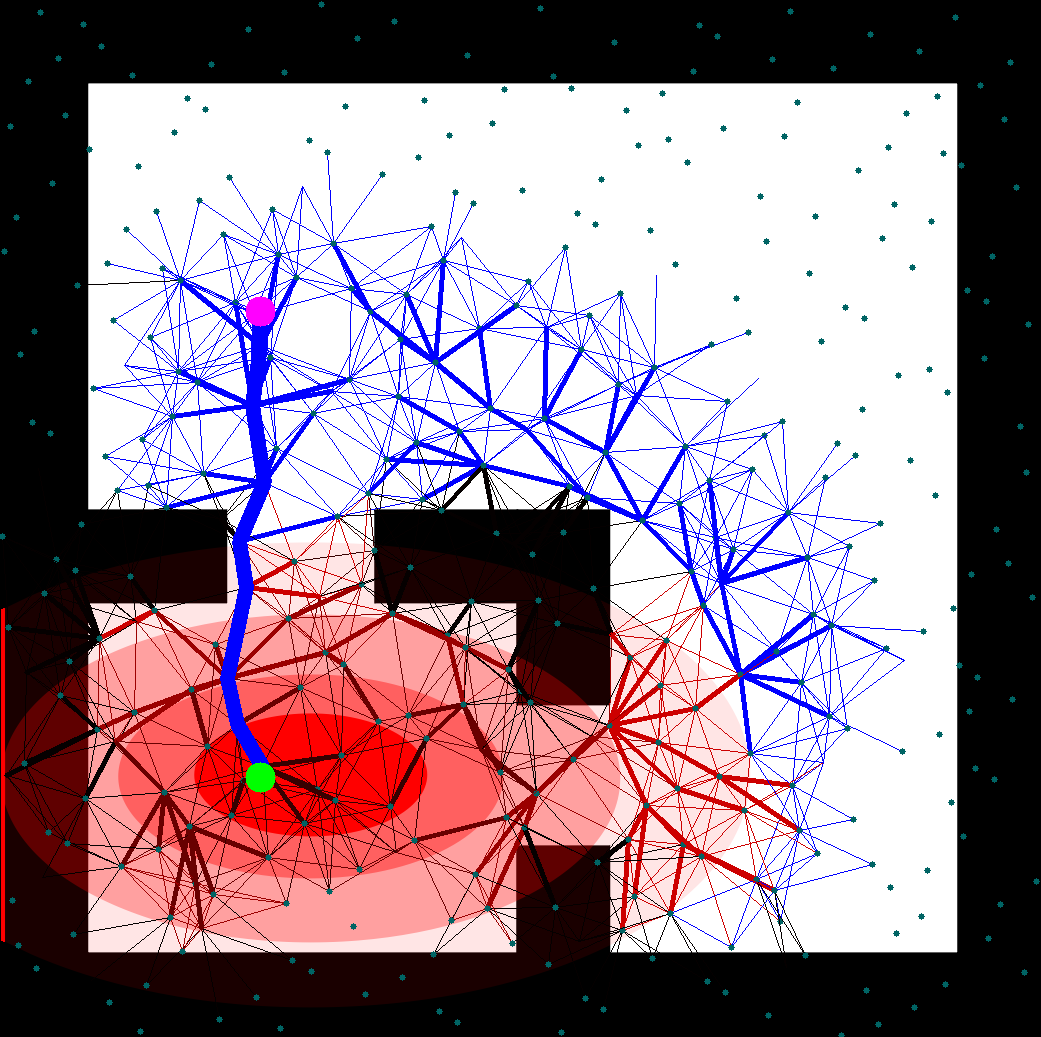
Class-Ordered A* and Class-Ordered LPA*: incremental search on weighted coloured graphs, implemented in OMPL.
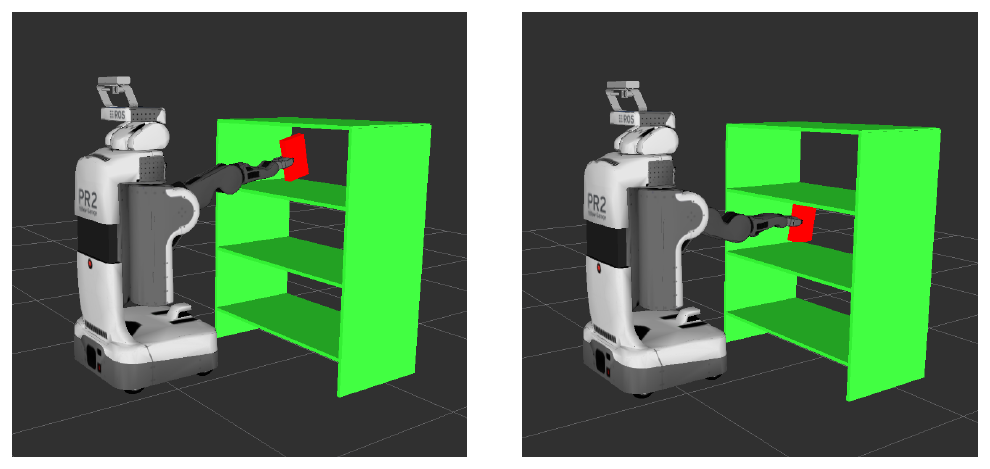
Multiscale planning and mapping on probabilistic obstacle maps, as a ROS package.
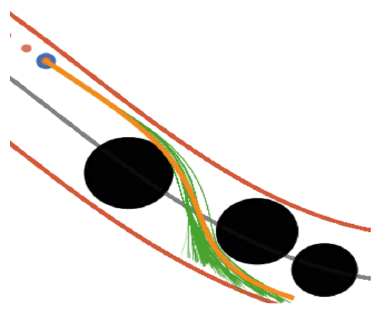
Sampling-based MPC with neural control barrier functions, for safety beyond the planning horizon.
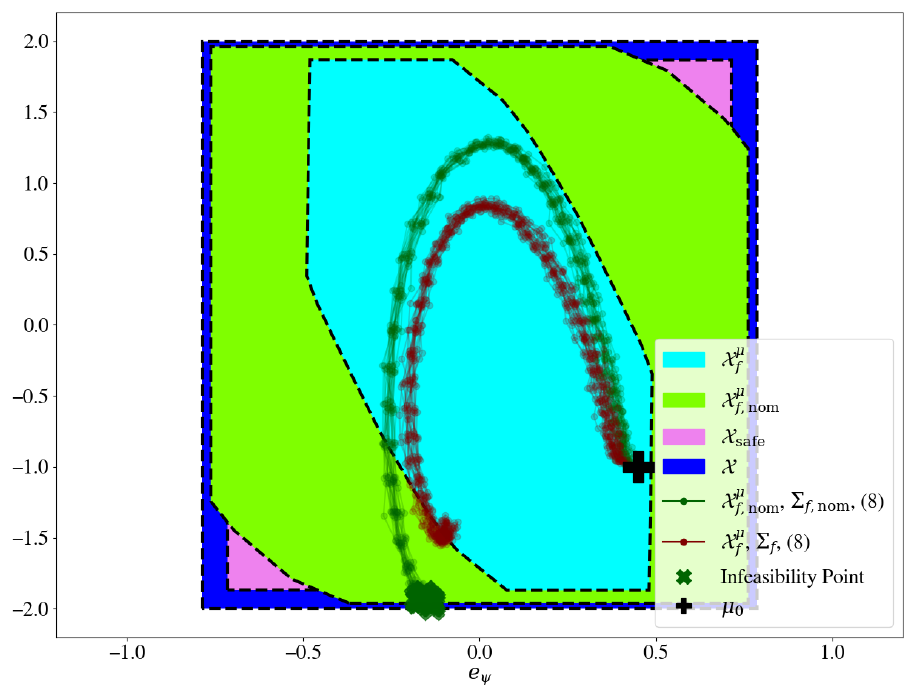
Reference implementation of recursively feasible stochastic MPC for time-varying linear systems under unbounded disturbances.
A closed-form Schrodinger bridge solver for problems whose boundary distributions are Gaussian mixtures.