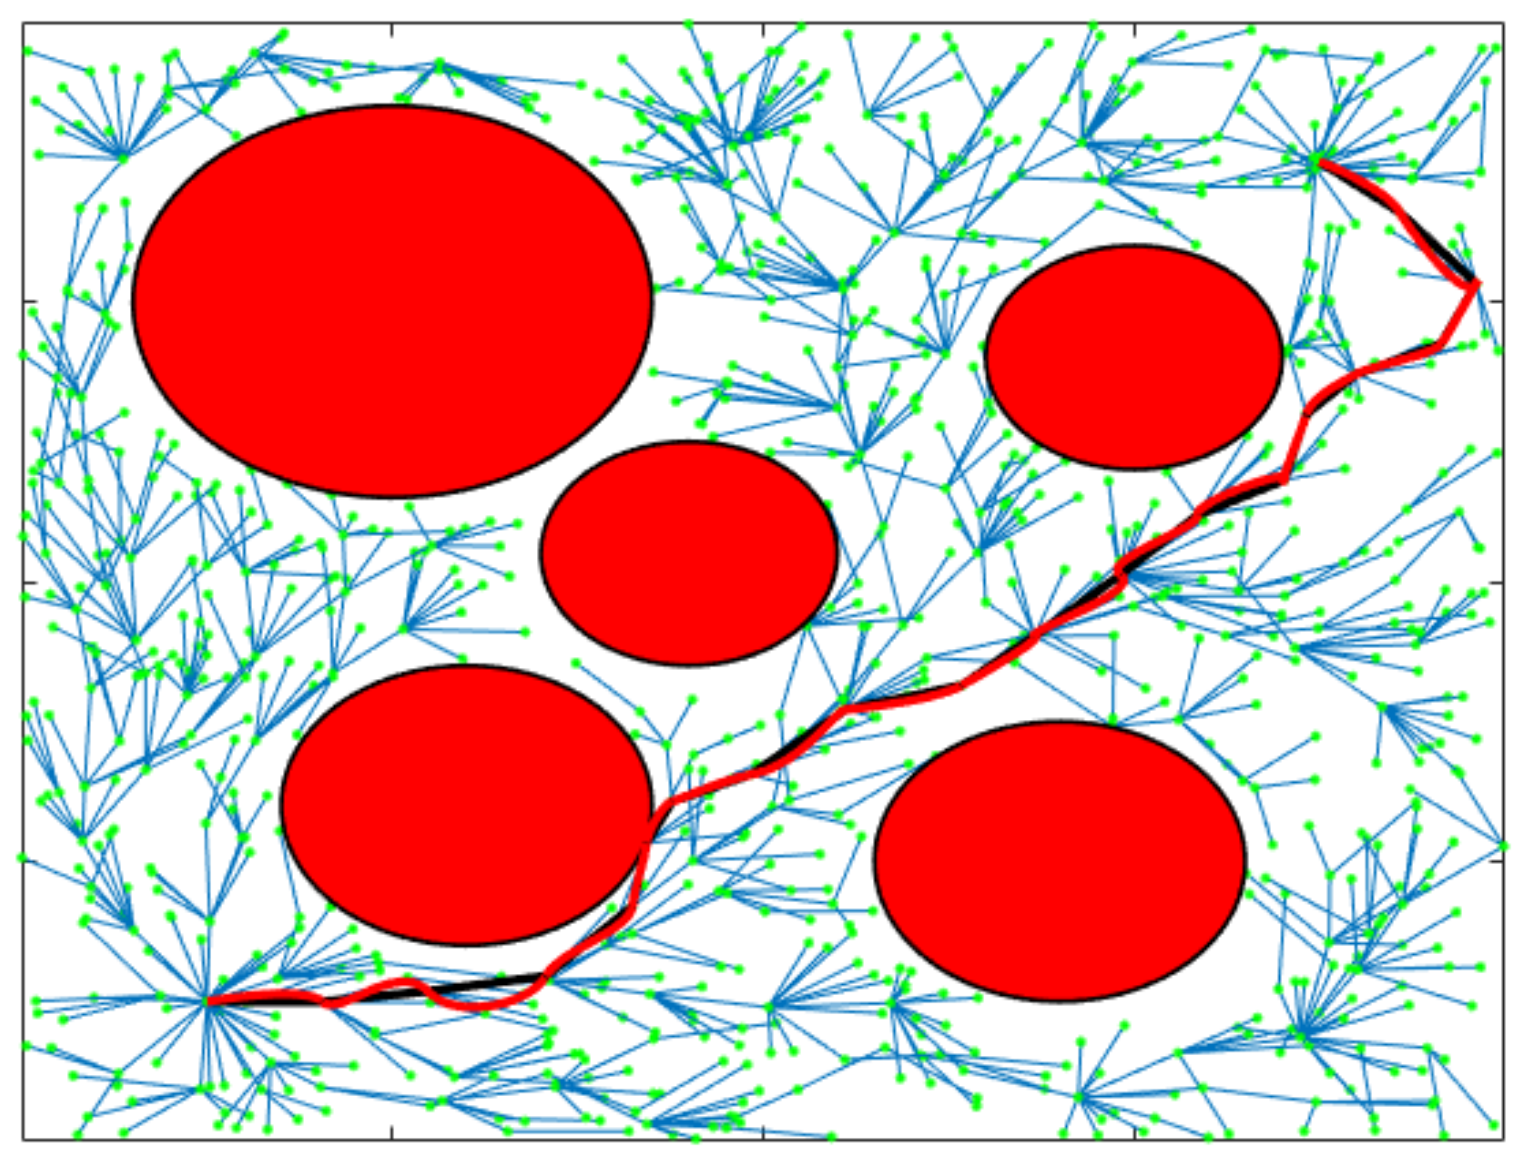
Learning-Based Kinodynamic RRT*
The two-point boundary value problem that connects a pair of samples has a closed-form solution only for simple linear systems, and solving it numerically dominates the cost of kinodynamic planning as the dynamics grow more complex. Here it is learned instead: optimal trajectories computed offline train a neural network controller, which then serves as the steering routine inside a kinodynamic RRT*.
The repository contains MATLAB implementations, including a three-dimensional case and a planar quadrotor.
Reference
D. Zheng and P. Tsiotras, “Sampling-based Kinodynamic Motion Planning Using a Neural Network Controller,” AIAA SciTech Forum, Guidance, Navigation, and Control, 2021.
See the Robust Autonomy for Uncertain Systems using Randomized Search project page for the wider context.
Visit the GitHub repository for the source code.