Multi-Resolution Multi-Agent A* (MAMS-A*)
MAMS-A* is a scalable shortest path planning algorithm designed for multi-agent systems operating in multi-scale environments. Presented at ICRA 2020, this algorithm leverages wavelet-based cell decompositions to efficiently plan paths for large teams of agents.
Key Features
- Multi-Resolution Graph: Constructs graphs with varying resolution based on agent proximity and environment complexity.
- Scalability: Efficiently handles large numbers of agents by reducing the search space in non-critical areas.
- ROS Integration: Built as a ROS package for easy deployment on robot teams.
- Wavelet Decomposition: Uses wavelet transforms to generate multi-scale representations of the cost map.
Applications
- Multi-robot path planning in large environments
- Search and rescue missions with heterogeneous teams
- Large-scale swarm coordination
Technical Details
- Language: C++
- Dependencies: ROS (Robot Operating System), OpenCV
- Algorithm: A* search on multi-resolution graphs
Visit the GitHub repository for source code and installation instructions.
Gallery
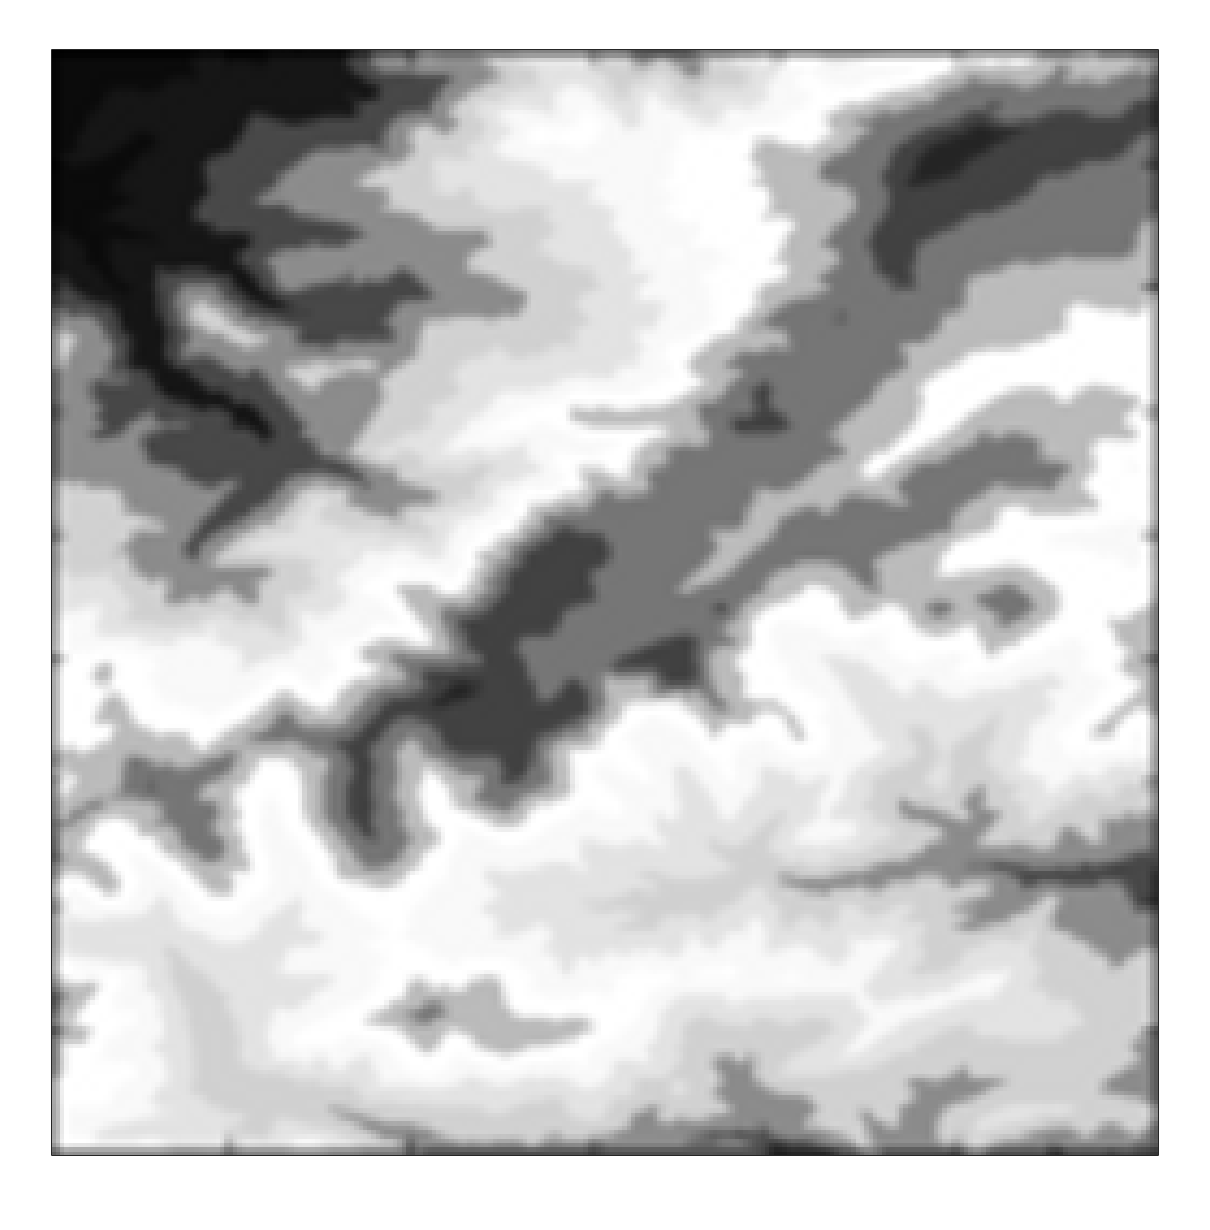 original_map.png