IBBT
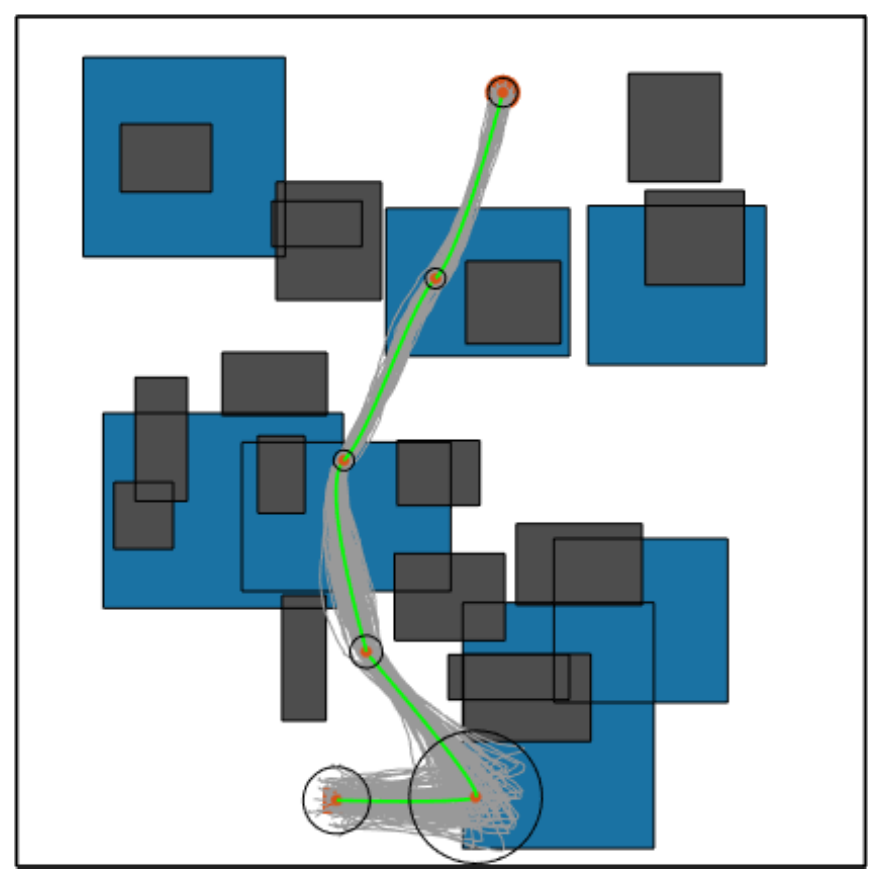
IBBT implements Informed Batch Belief Trees, an algorithm for motion planning under motion and sensing uncertainty. Rather than growing a single belief tree, it interleaves batches of samples with a heuristic search over the belief space, so that effort concentrates on the region that can still improve the solution.
The repository holds MATLAB implementations and simulations, including analytical double-integrator cases with and without landmarks, a Dubins vehicle, and comparisons against MCMP and RRBT. Released under the MIT license.
Reference
D. Zheng and P. Tsiotras, “IBBT: Informed Batch Belief Trees for Motion Planning Under Uncertainty,” IEEE International Conference on Robotics and Automation, Yokohama, Japan, 2024.
See the Robust Autonomy for Uncertain Systems using Randomized Search project page for the wider context.
Visit the GitHub repository for the source code.