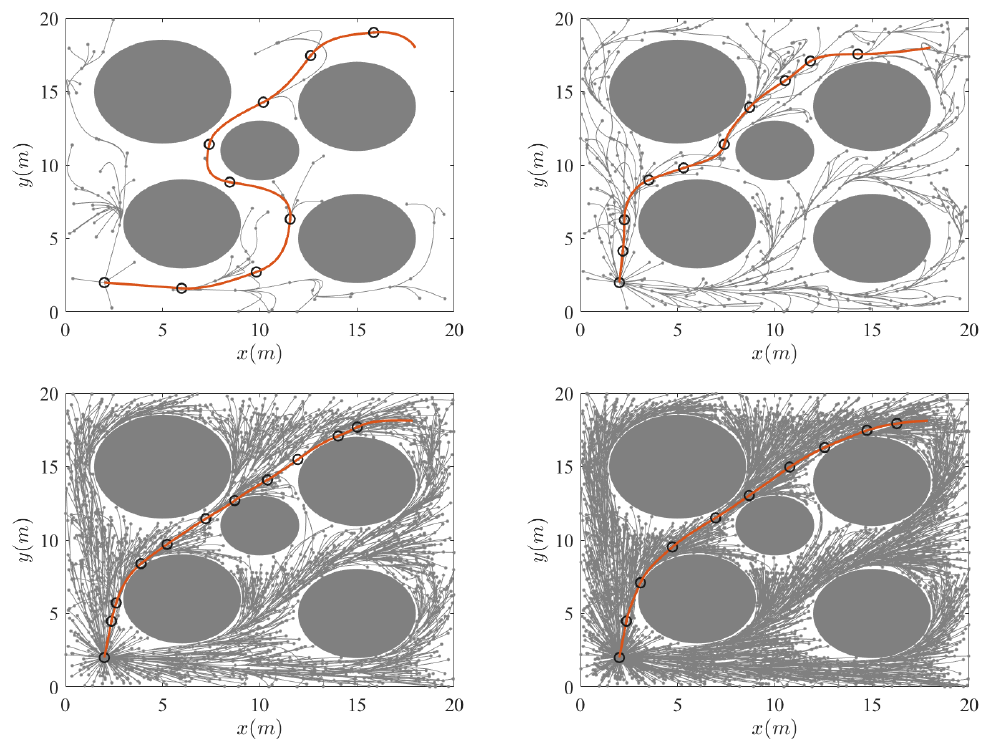
Kino-RRT*
Kino-RRT* reduces the dimension of the sampling space for kinodynamic motion planning by steering with a partial-final-state-free optimal controller, for which the repository’s authors derived an analytical solution in the linear case. Only the states that matter for the connection need to be sampled, which is where the speed-up comes from.
Three examples are provided — a two-dimensional double integrator, a three-dimensional double integrator and a linearized quadrotor — along with an implementation of conventional kinodynamic RRT* for comparison. MATLAB, MIT license.
Reference
D. Zheng and P. Tsiotras, “Accelerating Kinodynamic RRT* Through Dimensionality Reduction,” IEEE/RSJ International Conference on Intelligent Robots and Systems, Prague, Czech Republic, Sept. 27 – Oct. 1, 2021. doi:10.1109/IROS51168.2021.9636754 · PDF
See the Robust Autonomy for Uncertain Systems using Randomized Search project page for the wider context.
Visit the GitHub repository for the source code.