Lazy Incremental Search
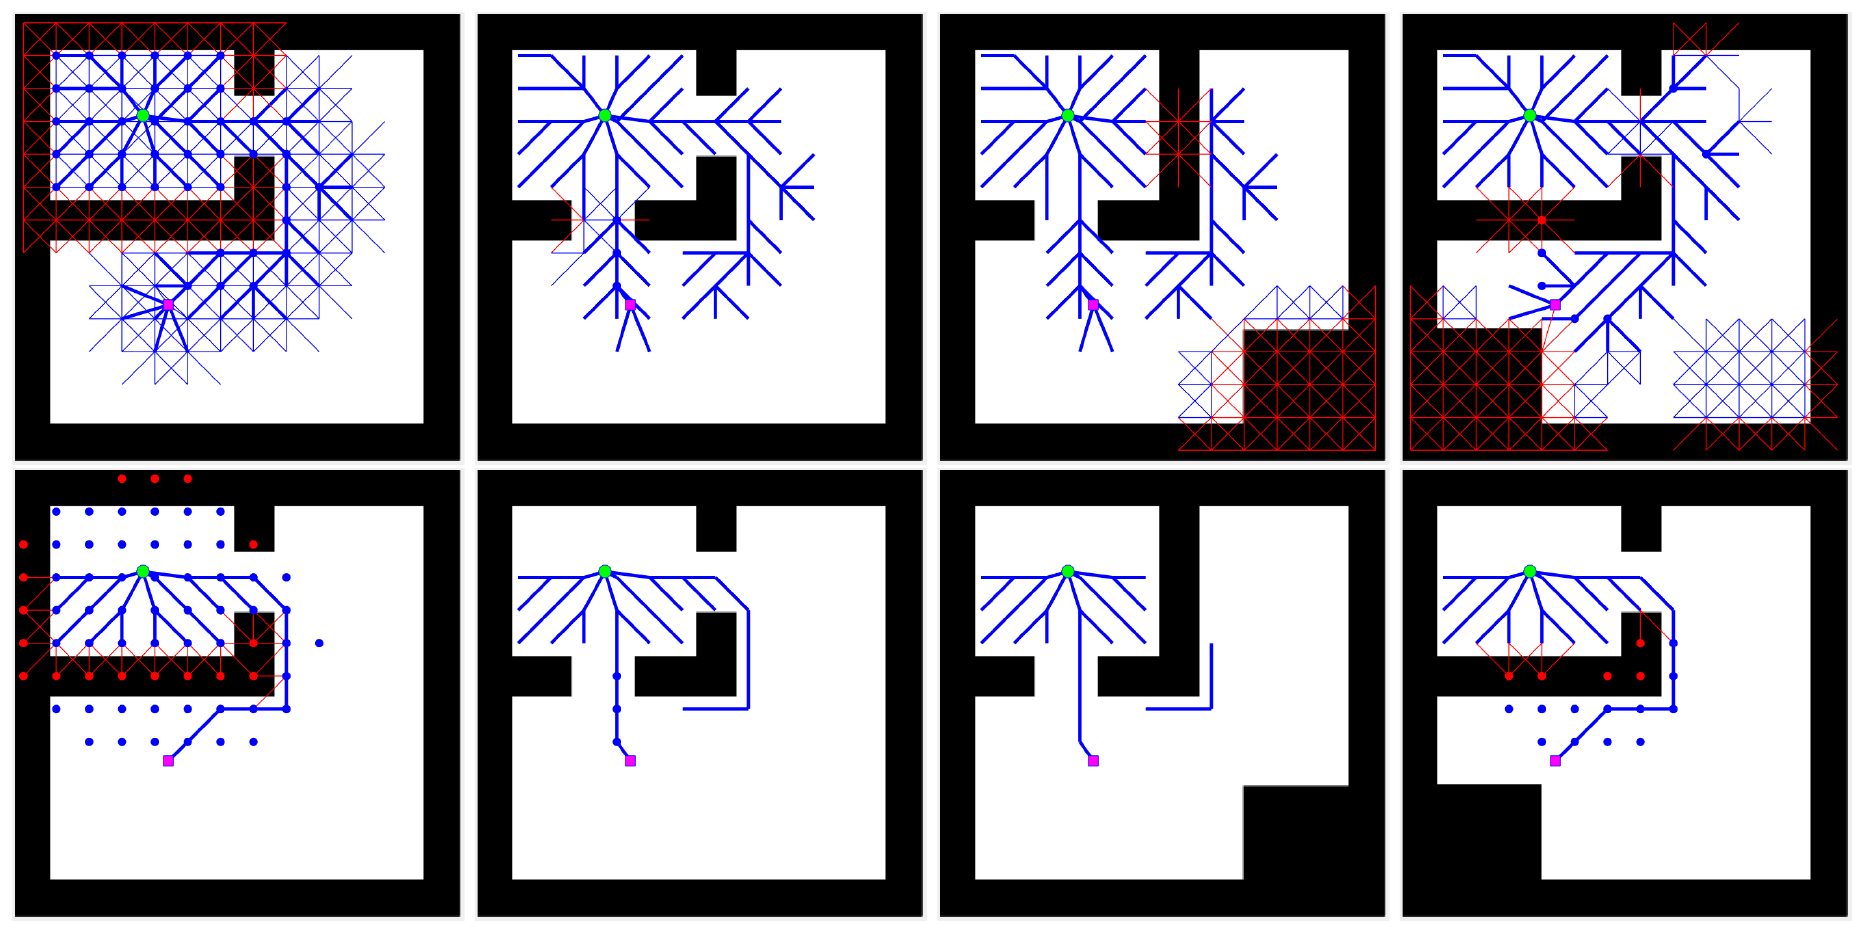
This framework implements several lazy search algorithms as OMPL planners, aimed at replanning problems where evaluating an edge is far more expensive than expanding a vertex. Three planners are provided: LPA*, the original Lifelong Planning A*; GLS, Generalized Lazy Search; and LGLS, Lifelong-GLS, which combines the vertex efficiency of the former with the edge efficiency of the latter. Each returns the shortest path on the roadmap graph it is planning over.
It depends on C++11, CMake, OMPL and the Boost Graph Library, and builds with catkin. Example graphs and environments are included.
Reference
J. Lim, M. Ghanei, R. C. Lawson, S. Srinivasa and P. Tsiotras, “Lazy Incremental Search for Efficient Replanning with Bounded Suboptimality Guarantees,” 2024.
See the Robust Autonomy for Uncertain Systems using Randomized Search project page for the wider context.
Visit the GitHub repository for the source code.