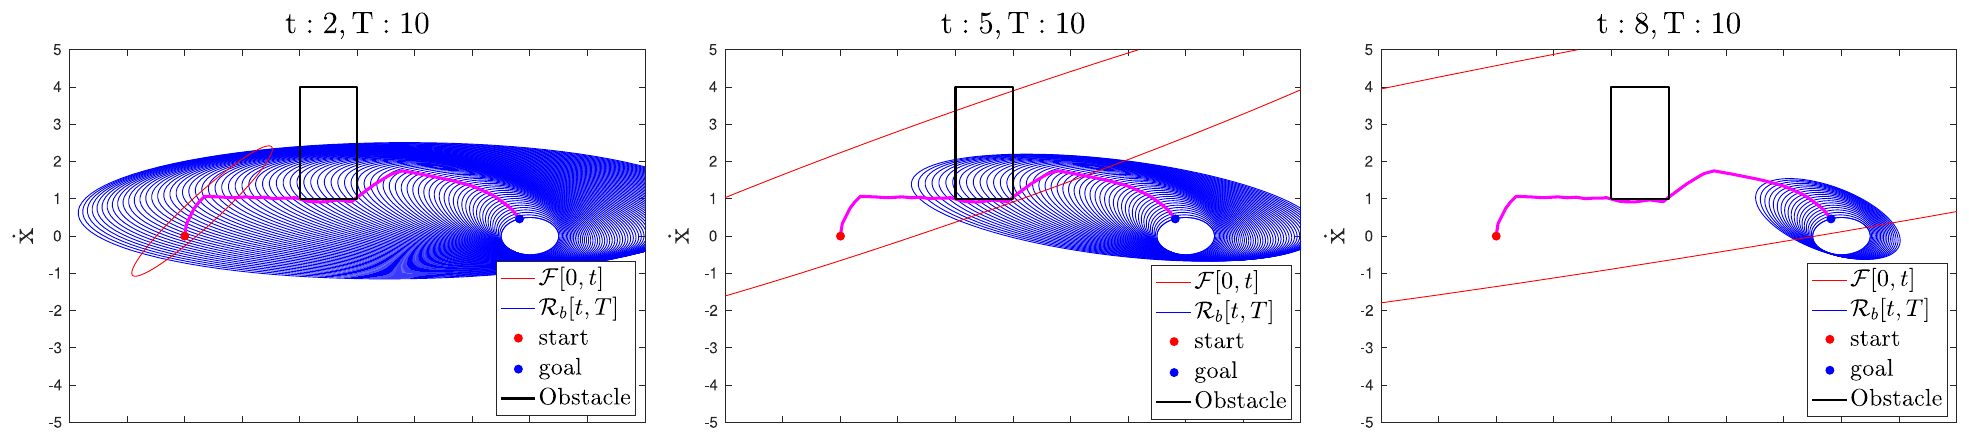
TIE
TIE implements Time-Informed Exploration, which uses ideas from reachability analysis to focus the search in sampling-based kinodynamic motion planning. Once an initial solution exists, the time-informed set contains every trajectory that could still improve on it, so sampling outside that set is provably redundant.
The repository is a ROS catkin package built on the Open Motion Planning Library (OMPL), with a Python script for plotting the resulting paths.
Reference
S. Joshi, S. Hutchinson and P. Tsiotras, “TIE: Time-Informed Exploration for Robot Motion Planning,” IEEE Robotics and Automation Letters, Vol. 6, No. 2, 2021, and the corresponding ICRA paper.
See the Robust Autonomy for Uncertain Systems using Randomized Search project page for the wider context.
Visit the GitHub repository for the source code.