COLPA*
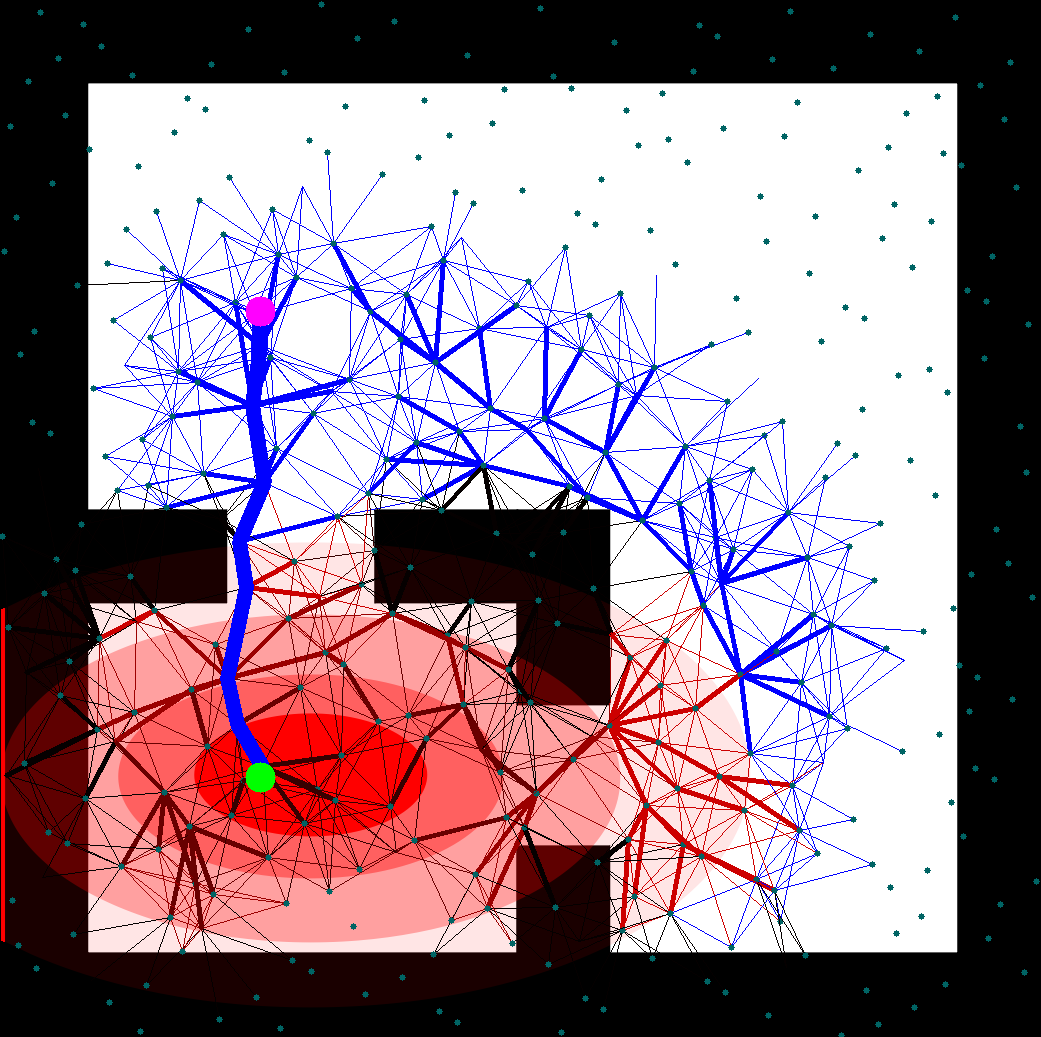
COLPA* is Lifelong Planning A* on weighted coloured graphs: edges carry a class as well as a cost, and the search orders candidate paths first by class and only then by weight. That makes it suited to navigation where some regions are categorically preferable to others rather than merely more expensive.
The planners are implemented in OMPL and return the shortest path on the roadmap graph being searched. The package depends on C++11, CMake, OMPL and the Boost Graph Library, builds with catkin, and ships an example graph and environment.
Reference
J. Lim, O. Salzman and P. Tsiotras, “Class-Ordered LPA*: An Incremental-Search Algorithm for Weighted Colored Graphs,” IEEE/RSJ International Conference on Intelligent Robots and Systems, 2021.
Visit the GitHub repository for the source code.