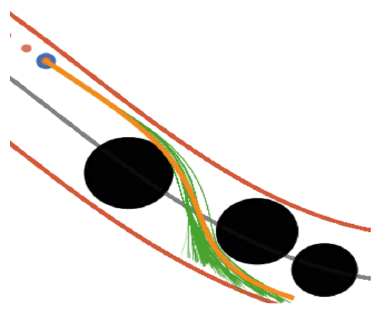
NS-VIMPC
Sampling-based model predictive control is fast but myopic: a trajectory that looks safe over the horizon can commit the vehicle to a state from which no safe continuation exists. This code pairs sampling-based MPC with a neural control barrier function, which certifies safety beyond the end of the horizon, and resamples against that certificate.
The repository reproduces the paper’s simulations, covering AutoRally, a planar quadrotor and a Dubins car, together with the scripts that train and evaluate the neural CBF and collect the offline data. Python with JAX and PyTorch; MIT license.
References
J. Yin, O. So, E. Y. Yu, C. Fan and P. Tsiotras, “Safe Beyond the Horizon: Efficient Sampling-based MPC with Neural Control Barrier Functions,” Robotics: Science and Systems, Los Angeles, CA, 2025.
J. Yin, C. Dawson, C. Fan and P. Tsiotras, “Shield Model Predictive Path Integral: A Computationally Efficient Robust MPC Method Using Control Barrier Functions,” IEEE Robotics and Automation Letters, Vol. 8, No. 11, pp. 7106–7113, 2023.
Visit the GitHub repository for the source code.