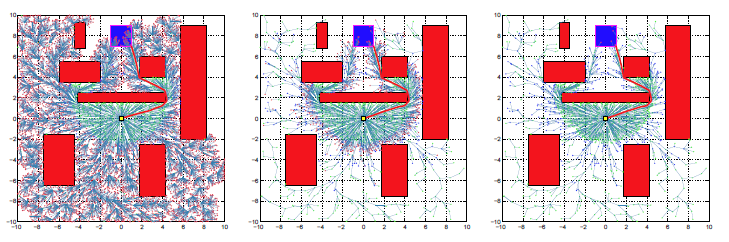
RRT# (RRT-Sharp)
RRT# is an asymptotically optimal sampling-based motion planning algorithm that guarantees convergence to the optimal path. It extends the RRT* algorithm by efficiently managing the graph structure to allow for rapid replanning and convergence.
Key Features
- Asymptotic Optimality: Converges to the optimal solution as the number of samples increases.
- Efficient Replanning: Capable of adapting the tree structure dynamically.
- Graph Management: Maintains a consistent graph for optimal path extraction.
- Standard Implementation: Provides a reference implementation of the algorithm.
Applications
- High-dimensional motion planning
- Robot arm manipulation
- Autonomous navigation in cluttered environments
Technical Details
- Language: C++
- Algorithm: RRT# (Rapidly-exploring Random Graph)
- Dependencies: Standard C++ libraries
Visit the GitHub repository for the source code and examples.