mapnplan
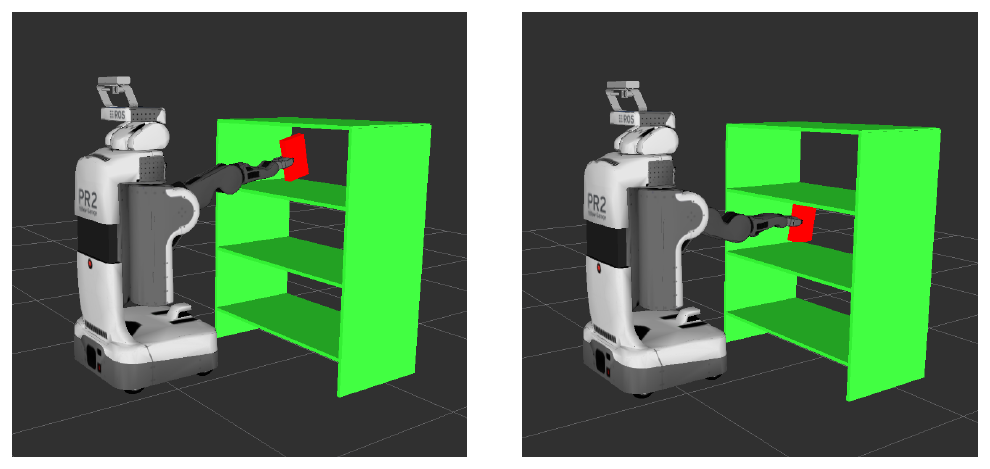
mapnplan implements multiscale planning and mapping as a ROS package, pairing a multiscale planner with the mapping that feeds it so that perception and planning share one representation of the environment at several resolutions. The repository contains the three-dimensional multiscale planner, the planning node and the conversion from laser scans to point clouds, and depends on roscpp, gazebo_ros, laser_geometry, tf, octomap and ros_control.
The repository’s own README is a title only; the description above is drawn from the associated papers.
References
F. Hauer, A. Kundu, J. Rehg and P. Tsiotras, “Multi-scale Perception and Path Planning on Probabilistic Obstacle Maps,” IEEE International Conference on Robotics and Automation, 2015.
F. Hauer and P. Tsiotras, “Reduced Complexity Multi-Scale Path-Planning on Probabilistic Maps,” IEEE International Conference on Robotics and Automation, 2016.
Visit the GitHub repository for the source code.