The Uncertainty Synthesis for Trusted Autonomy research area focuses on developing formal methods, theoretical frameworks, and algorithms that enable autonomous systems with learning-enabled components to operate reliably and safely under uncertainty. Our work bridges control theory, machine learning, and formal verification to create trustworthy autonomous systems.
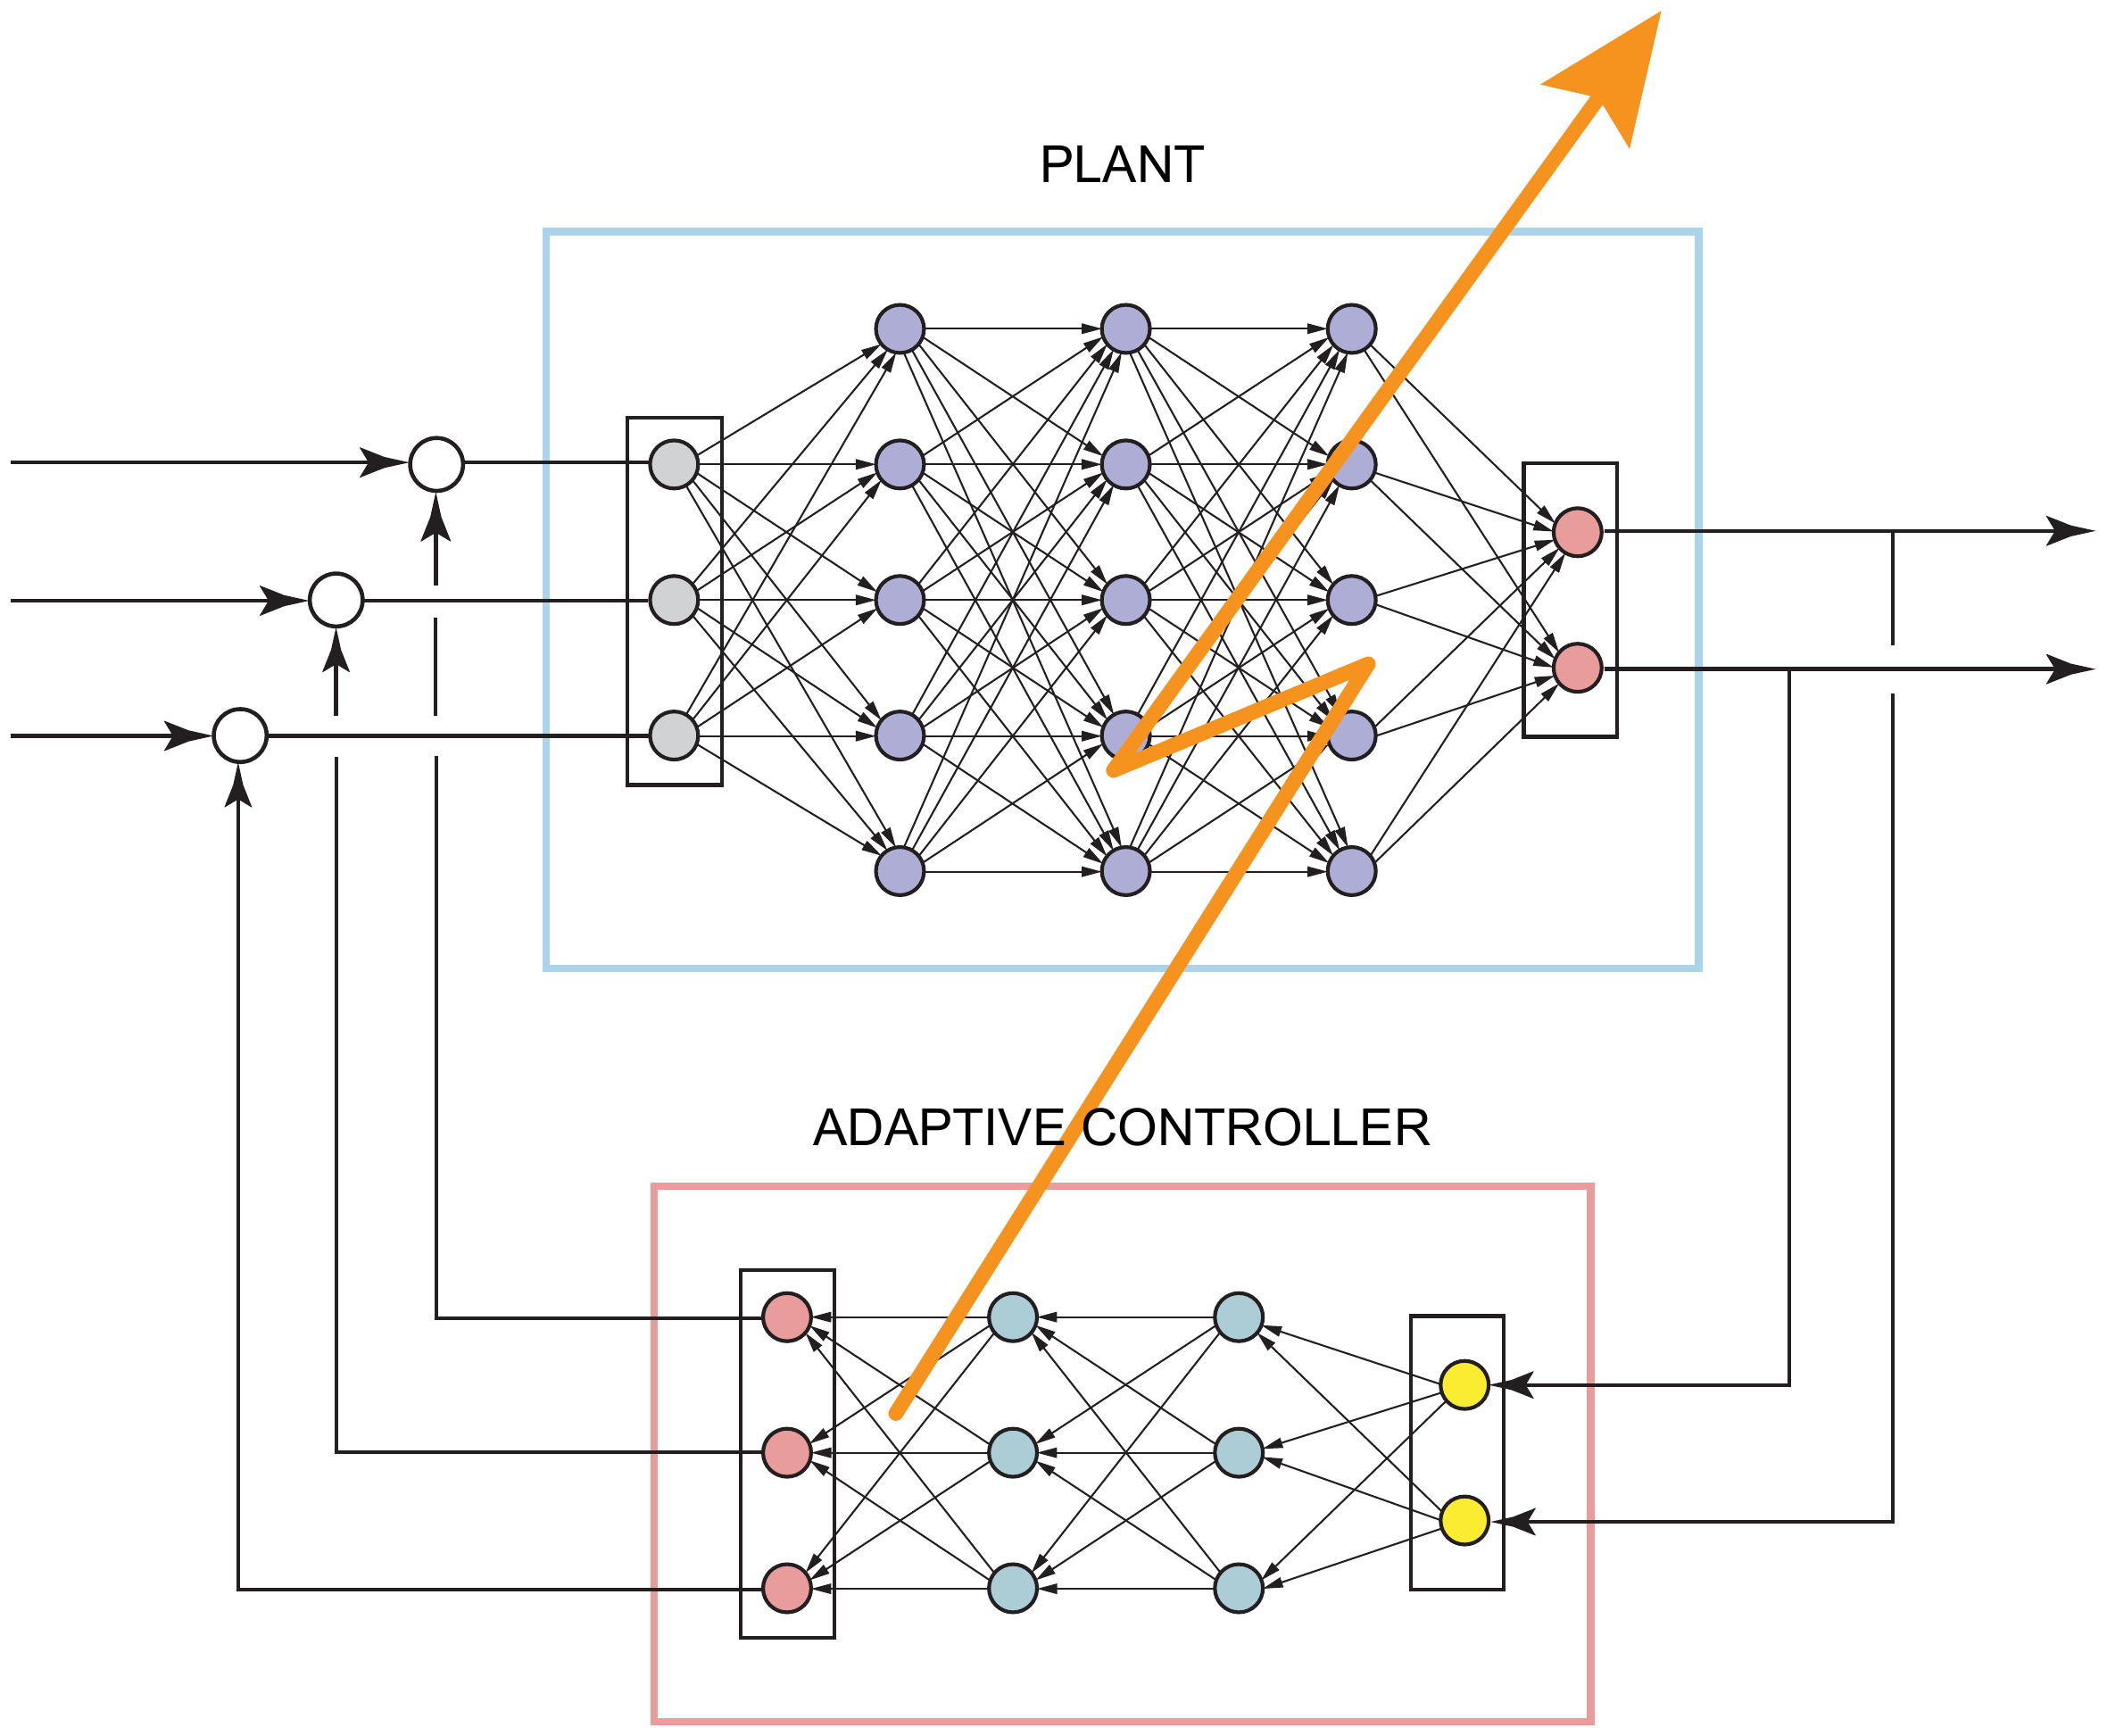
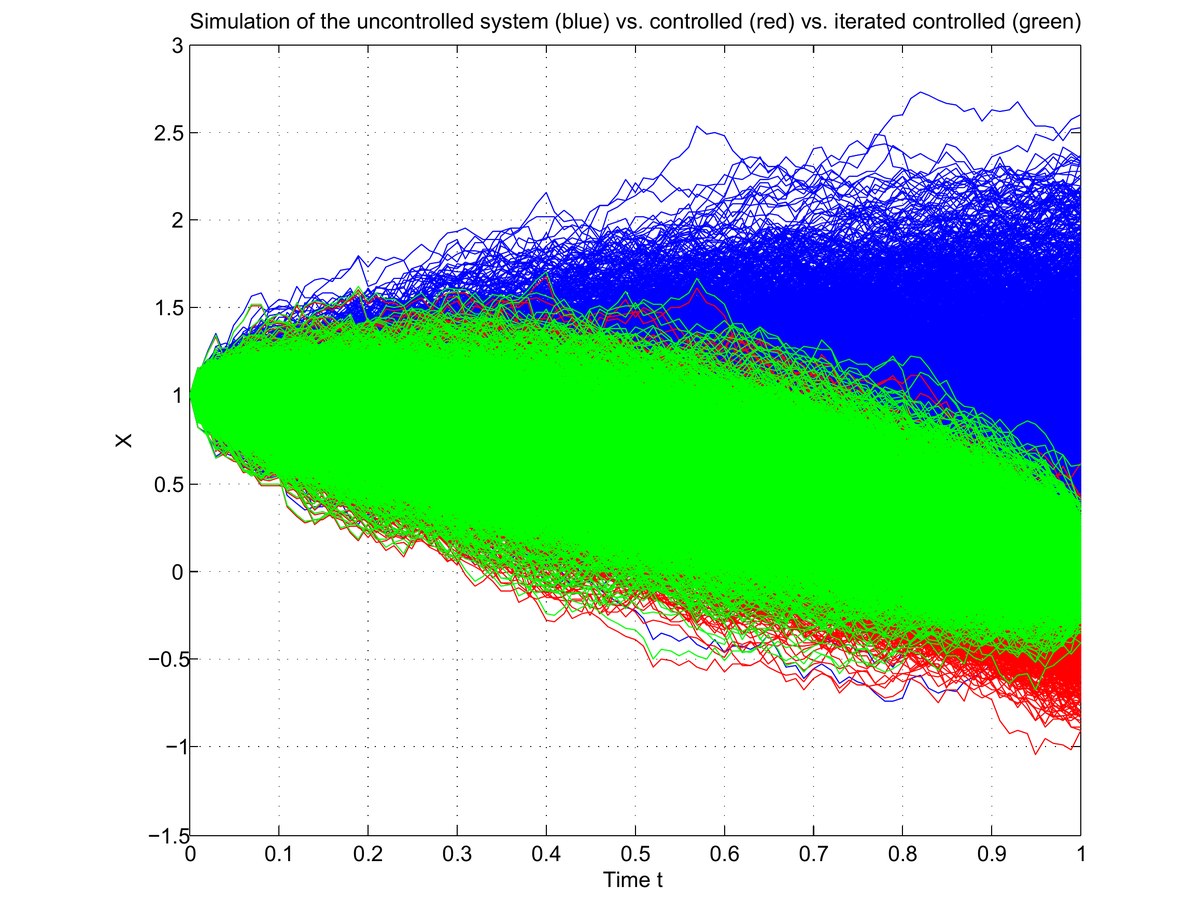
Our core research addresses safety assurances for learning-enabled components, optimal control under parameter uncertainty, stochastic optimal control for uncertain dynamics, and formal verification of autonomous systems. We develop statistical and probabilistic methods for learning algorithmic controllers, sensitivity analysis for robust control, and recovery methods for systems that encounter unexpected conditions.
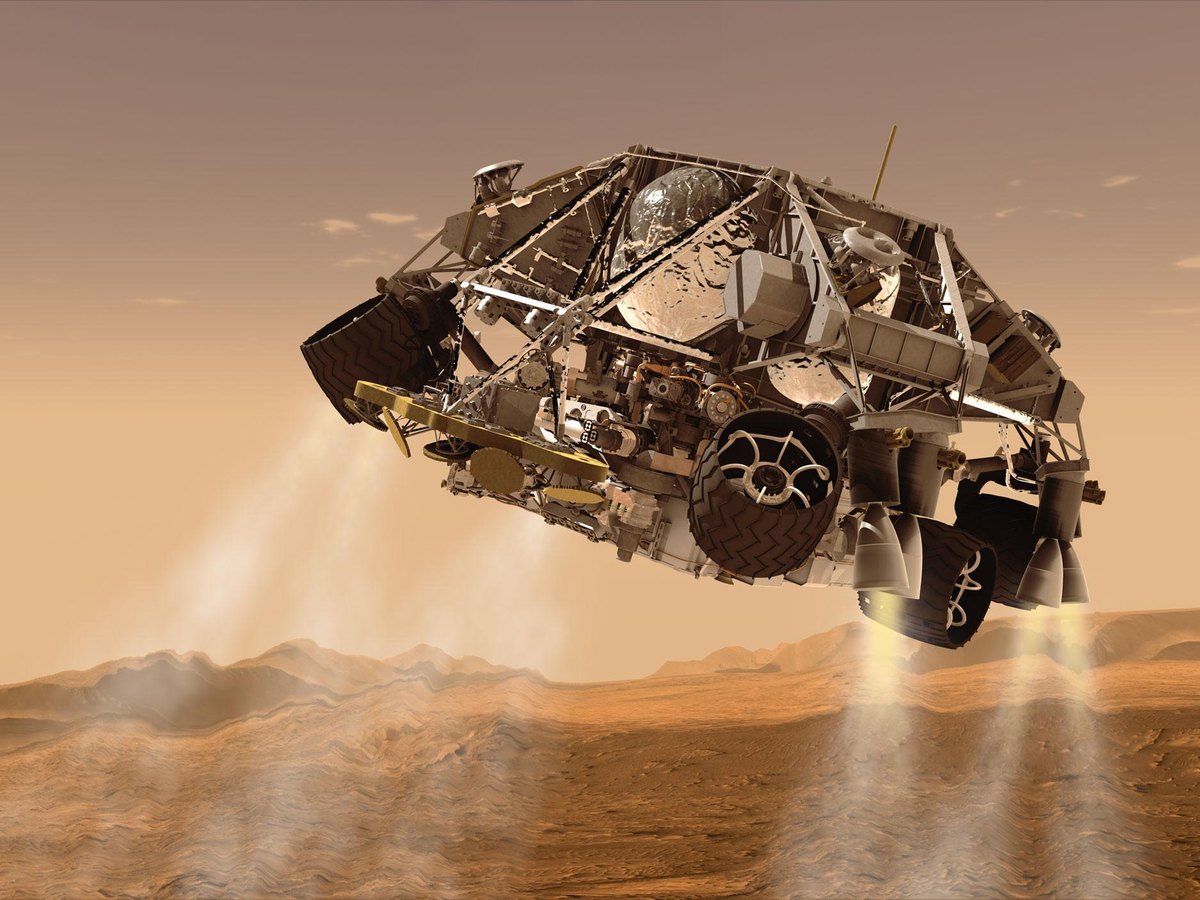
Applications include aviation autonomy, powered descent guidance for spacecraft landing, autonomous vehicles with AI components, and robust recovery mechanisms. Our work emphasizes both theoretical guarantees and practical validation, with close collaboration with aerospace and automotive partners to transition technologies to real-world systems.