Research Area

Intelligent Decision-Making and Control

How machines decide under incomplete information - bounded rationality, learning, and control that adapts in real time

9 Selected Projects
37 Selected Publications

This research area focuses on developing intelligent decision-making frameworks and adaptive control strategies for autonomous agents operating in complex environments. We integrate classical control theory with modern machine learning and decision theory to create systems that can reason about uncertainty, learn from experience, and adapt their behavior in real-time.

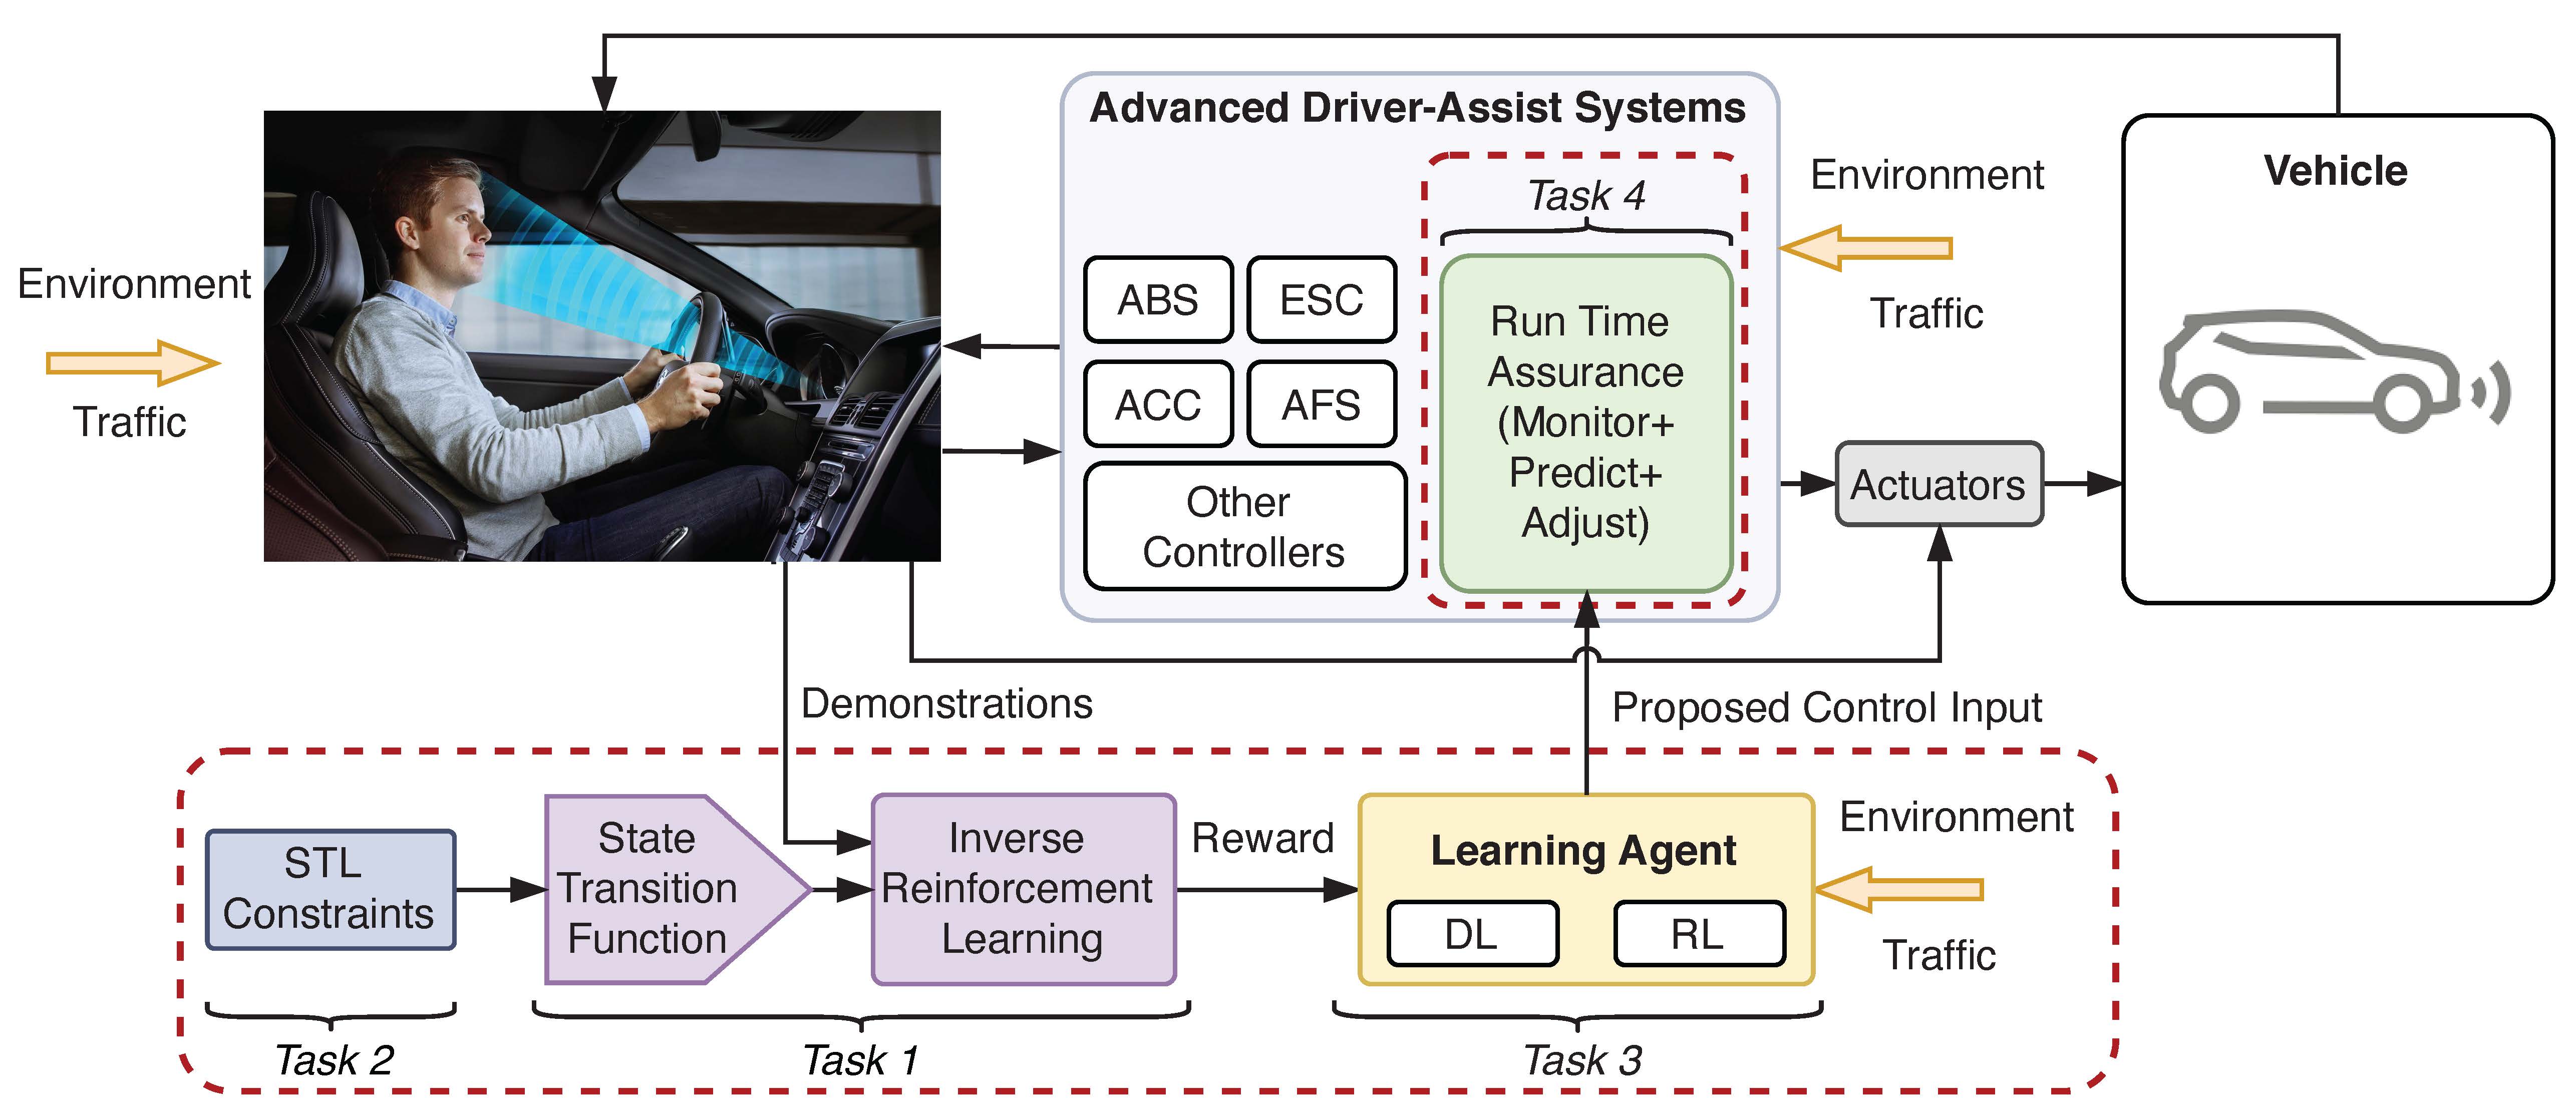
Our research encompasses formal methods for safety assurance, bounded-rational decision models, learning-enabled components with formal guarantees, and hierarchical control architectures for autonomous systems. We develop techniques for handling incomplete information, adversarial scenarios, and human-in-the-loop decision-making.

Applications include autonomous vehicles, assistive robotics, cyber-physical systems, and human-agent collaboration. Our work emphasizes both theoretical foundations and practical implementation on real robotic platforms and autonomous vehicles.
Selected Projects
Selected Publications
1.

Guan, Y., Zhou, M., Pakniyat, A., and Tsiotras, P. “Shaping Large Population Agent Behaviors Through Entropy-Regularized Mean-Field Games,” American Control Conference, Atlanta, GA, June 8-10 , 2022.

2.

Maity, D., and Tsiotras, P., “Optimal Controller Synthesis and Dynamic Quantizer Switching for Linear Quadratic-Gaussian Systems,” IEEE Transactions on Automatic Control, Vol. 67, No. 1, pp. 382-389, 2022.

3.

Sivaramakrishnan, V., Pilipovsky, J., Oishi, M., and Tsiotras, P., “Distribution Steering for Discrete-Time Linear Systems with General Disturbances using Characteristic Functions,” American Control Conference, Atlanta, GA, June 8-10 , 2022.

4.

Yin, J., Zhang, Z., Theodorou, E., and Tsiotras, P., “Trajectory Distribution Control for Model Predictive Path Integral Control using Covariance Steering,” International Conference on Robotics and Automation, Philadelphia, PA, May 23-27, 2022.

5.

Guan, Y., Maity, D., Kroninger, C., and Tsiotras, P., “Bounded-Rational Pursuit-Evasion Games,” American Control Conference, New Orleans, LA, May 26-28, 2021, pp. 3216-3221.

6.

Larsson, D., and Maity, D., and Tsiotras, P., “Information-Theoretic Abstractions for Planning for Agents with Computational Constraints,” IEEE Robotics and Automation Letters, Vol. 6, No. 4, pp. 7651-7658, 2021.

7.

Lim, J., Salzman, O., and Tsiotras, P., “Class-Ordered LPA : An Incremental-Search Algorithm for Weighted Colored Graphs,” IEEE/RSJ International Conference on Intelligent Robots and Systems, Prague, Czech Republic, Sept. 27-Oct. 1, 2021.

8.

Lim, J., and Tsiotras, P., “A Generalized A* Algorithm for Finding Globally Optimal Paths in Weighted Colored Graphs,” International Conference on Robotics and Automation, Xi'an, China, May 30-June 5, 2021.

9.

Pakniyat, A., and Tsiotras, P., “Partially Observed Steering the State of Linear Stochastic Systems,” 60th IEEE Conference on Decision and Control, Austin, TX, Dec.13-15, 2021, pp. 3780-3785.

10.

Pakniyat, A., and Tsiotras, P., “Steering the State of Linear Stochastic Systems: A Constrained Minimum Principle Formulation,” American Control Conference, New Orleans, LA, May 26-28, 2021.

11.

Pilipovsky, J. and Tsiotras, P., “Chance-Constrained Optimal Covariance Steering with Iterative Risk Allocation,” American Control Conference, New Orleans, LA, May 26-28, 2021, pp. 2011-2016.

12.

Pilipovsky, J., and Tsiotras, P. “Covariance Steering with Optimal Risk Allocation,” IEEE Transactions on Aerospace and Electronic Systems, Vol. 57, No. 6, pp. 3719-3733, 2021.

13.

You, C., and Tsiotras, P., “High-Speed Cornering for Autonomous Off-Road Rally Racing,” IEEE Transactions on Control Systems Technology, Vol. 29, No. 2, pp. 485-501, 2021.

14.

Zhang, Q., Guan, Y., and Tsiotras, P., “Learning Nash Equilibria in Zero-Sum Stochastic Games via Entropy-Regularized Policy Approximation,” 30th International Joint Conference on Artificial Intelligence, Montreal, Canada, Aug. 21-26, 2021, pp. 2462-2468.

15.

Lim, J., and Tsiotras, P., “MAMS-A*: Multi-Agent Multi-Scale A*,” International Conference on Robotics and Automation, Paris, France, May 31-June 4, 2020.

16.

Ridderhof, J., Okamoto, K., and Tsiotras, P., “Chance Constrained Covariance Control for Linear Stochastic Systems With Output Feedback,” 59th IEEE Conference on Decision and Control, Jeju Island, South Korea, Dec. 8-11, 2020.

17.

You, C., Lu, J., Filev, D., and Tsiotras, P., “Autonomous Planning and Control for Intelligent Vehicles in Traffic,” IEEE Transactions on Intelligent Transportation Systems, Vol. 21, No. 6, pp. 2339-2349, June 2020.

18.

Makkapati, V. R., Sarabu, H., Comandur, V., Tsiotras, P., and Hutchinson, S., “Safe Optimal Control under Parametric Uncertainties,” IEEE Robotics and Automation Letters, Vol. 5, No. 4, pp. 5725-5731, 2019.

19.

Okamoto, K. and Tsiotras, P., “Input Hard Constrained Optimal Covariance Steering,” 58th IEEE Conference on Decision and Control, Nice, France, Dec. 11-13, 2019.

20.

Okamoto, K. and Tsiotras, P., “Optimal Stochastic Vehicle Path Planning Using Covariance Steering,” IEEE Robotics and Automation Letters, Vol. 4, No. 3, pp. 2276-2281, 2019.

21.

Ridderhof, J., Okamoto, K. and Tsiotras, P., “Nonlinear Uncertainty Control with Iterative Covariance Steering,” 58th IEEE Conference on Decision and Control, Nice, France, Dec. 11-13, 2019.

22.

Larsson, D., Kotsalis, G., and Tsiotras, P., “Nash and Correlated Equilibria for Pursuit- Evasion Games Under Lack of Common Knowledge,” 57th IEEE Conference on Decision and Control, Miami, FL, Dec. 17–19, 2018, pp. 3579–3584.

23.

You, C., and Tsiotras, P., “Real-Time Trail-Braking Maneuver Generation for Off-Road Vehicle Racing,” American Control Conference, Milwaukee, WI, June 27-29, 2018, pp. 4751– 4756.

24.

Larsson, D., Braun, D., and Tsiotras, P., “Hierarchical State Abstractions for Decision-Making Problems with Computational Constraints,” 56th IEEE Conference on Decision and Control, Melbourne, Australia, Dec. 12-15, 2017, pp. 1138-1143.

25.

You, C., and Tsiotras, P., “Vehicle Modeling and Parameter Estimation Using Adaptive Limited Memory Joint-State UKF,” American Control Conference, Seattle, WA, May 24-26, 2017, pp. 322-327.

26.

Exarchos, I., Tsiotras, P., and Pachter, M., “UAV Collision Avoidance based on the Solution of the Suicidal Pedestrian Differential Game,” AIAA Guidance, Navigation, and Control Conference, San Diego, CA, January 4-8, 2016.

27.

Okamoto, K., and Tsiotras, P., “A New Hybrid Sensorimotor Driver Model with Model Predictive Control,” IEEE Conference on Systems, Man and Cybernetics, Budapest, Hungary, Oct. 9-12, 2016, (best student paper finalist).

28.

You, C., Lu, J., and Tsiotras, P., “Driver Parameter Estimation Using Joint E-/UKF and Dual E-/UKF Under Nonlinear State Inequality Constraints,” IEEE Conference on Systems, Man and Cybernetics, Budapest, Hungary, Oct. 9-12, 2016.

29.

You, C., and Tsiotras, P., “Optimal Two-Point Visual Driver Model and Controller Development for Driver-Assist Systems for Semi-Autonomous Vehicles,” American Control Conference, Boston, MA, July 6-8, 2016.

30.

Arslan O., and Tsiotras, P., “Dynamic Programming Guided Exploration for Sampling-based Motion Planning Algorithms,” IEEE International Conference on Robotics and Automation, Seattle, WA, May 26-30, 2015, pp. 4819-4826.

31.

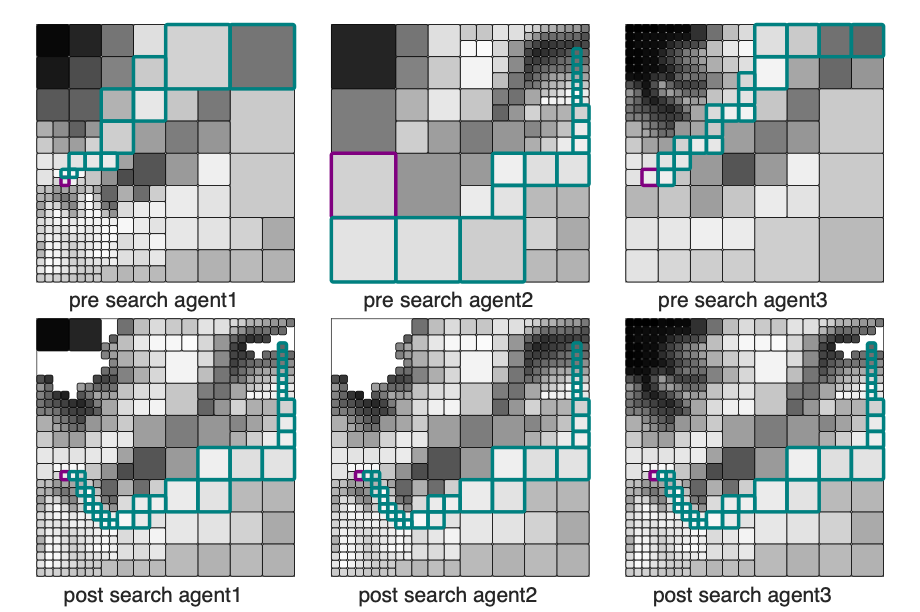
Hauer, F., Kundu, A., Rehg, J., and Tsiotras, P., “Multi-scale Perception and Path Planning on Probabilistic Obstacle Maps,” IEEE International Conference on Robotics and Automation, Seattle, WA, May 26-30, 2015, pp. 4210-4215.

32.

Sun, W., Theodorou, E. and Tsiotras, P., “Game Theoretic Continuous Time Differential Dynamic Programming,” American Control Conference, Chicago, IL, July 1-3, 2015, pp. 5593-5598.

33.

Sun, W., and Tsiotras, P., “Pursuit Evasion Game of Two Players under an External Flow Field,” American Control Conference, Chicago, IL, July 1-3, 2015, pp. 5617-5622.

34.

Arslan, O., Theodorou E., and Tsiotras, P. “Information-Theoretic Stochastic Optimal Control via Incremental Sampling-based Algorithms,” IEEE Symposium on Adaptive Dynamic Programming and Reinforcement Learning, Orlando, FL, Dec. 9-12, 2014, pp. 71-78.

35.

Exarchos, I., and Tsiotras, P., “An Asymmetric Version of the Two Car Pursuit-Evasion Game,” 53rd IEEE Conference on Decision and Control, Los Angeles, CA, Dec. 15-17, 2014, pp. 4272-4277.

36.

Sun, W., Theodorou, E., and Tsiotras, P., “Continuous-Time Differential Dynamic Programming with Terminal Constraints,” IEEE Symposium on Adaptive Dynamic Programming and Reinforcement Learning, Orlando, FL, Dec. 9-12, 2014, pp. 289-294.

37.

Sun, W. and Tsiotras, P., “An Optimal Evader Strategy in a Two-Pursuer One-Evader Problem,” 53rd IEEE Conference on Decision and Control, Los Angeles, CA, Dec. 15-17, 2014, pp. 4266-4271.