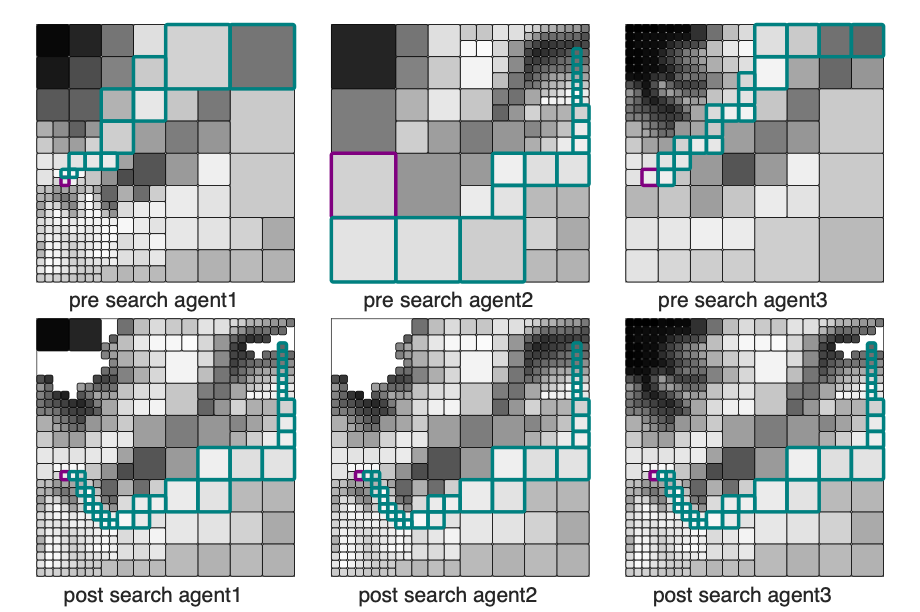
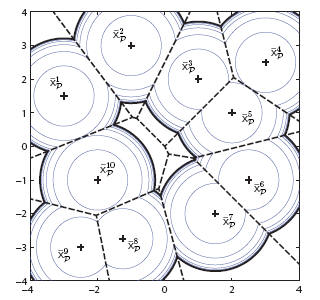
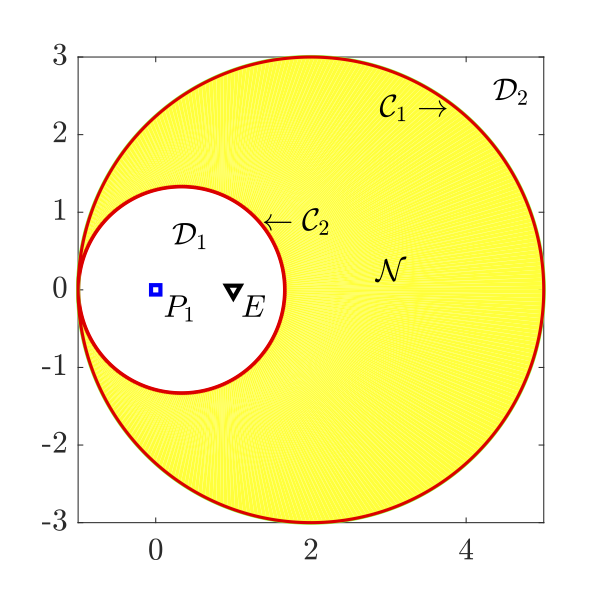
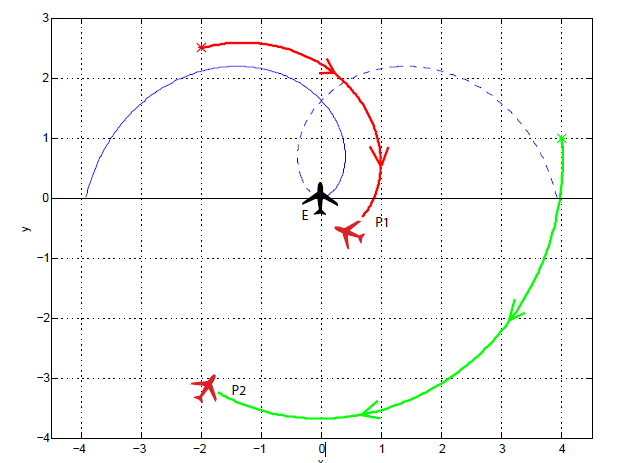
The Multi-Agent Systems and Stochastic Games research area develops algorithms and theoretical frameworks for coordinating teams of autonomous agents in competitive and cooperative scenarios. Our work spans from game-theoretic foundations and distributed optimization to practical applications in robotics, autonomous systems, and strategic planning.
Our core research addresses differential games for pursuit-evasion scenarios, stochastic games under uncertainty, distributed decision-making, swarm coordination, and communication-limited control. We develop algorithms for decentralized optimization, game-theoretic equilibrium strategies, resilient multi-agent systems, and hierarchical coordination architectures.
Applications include multi-robot coordination, swarm intelligence, autonomous transportation, competitive agent scenarios, and resilient networked systems. We provide rigorous mathematical frameworks with convergence guarantees, performance bounds, and algorithms that scale to large populations of autonomous agents.